Vladimir S. Aslanov
          aslanov_vs@mail.ru


Dynamics of satellite with
   a Tether System

  Theoretical Mechanics Department
            www.termech.ru

  Samara State Aerospace University,
               Russia
             www.ssau.ru


                 2012
Statement of the problem

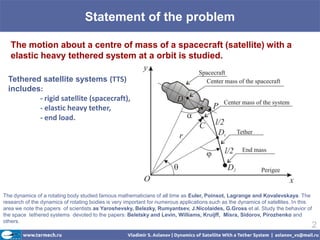
   The motion about a centre of mass of a spacecraft (satellite) with a
   elastic heavy tethered system at a orbit is studied.

  Tethered satellite systems (TTS)
  includes:
          - rigid satellite (spacecraft),
          - elastic heavy tether,
          - end load.


The dynamics of a rotating body studied famous mathematicians of all time as Euler, Poinsot, Lagrange and Kovalevskaya. The
research of the dynamics of rotating bodies is very important for numerous applications such as the dynamics of satellites. In this
area we note the papers of scientists as Yaroshevsky, Belezky, Rumyantsev, J.Nicolaides, G.Gross et al. Study the behavior of
the space tethered systems devoted to the papers: Beletsky and Levin, Williams, Kruijff, Misra, Sidorov, Pirozhenko and
others.
                                                                                                                                  2
Example of the Tethered Satellite Systems

               Scheme of the dynamic deployment of TSS
                    «Foton-М3" №3 – YES2" (2008)


Initial Foton-M3 parameters are assumed
as follows:
Mass                         6530 kg
Ballistic coefficient       0.0123 m2/kg.
Inclination                 63 degrees
Minimum orbital altitude       262 km
Maximum orbital altitude        304 km

Tether parameters are assumed as
follows:
Diameter                   0.5 mm
Length                     30000 m
Mass density               0.00018 kg/m
Initial Speed of
 tether deployment         2.58 m/c
Mass End Load              12 kg
                                                         3
Aims of the research


1. To obtain mathematical models of the plane motion of the satellite of
   about of mass center under the influence of elastic the tether system.
2. To deduce approximate analytical solutions describing
   the oscillations of the satellite caused by the change magnitude and
   direction of the tether force.
3. To build models chaotic behavior of the satellite and to study of the
   satellite motion under the influence the elastic tether of the chaotic
   dynamics methods.
4. To find the approximate estimates of the accelerations in the
   satellite arising from the deployment of the tether.


                                                                            4
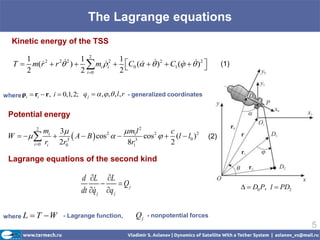
The Lagrange equations
   Kinetic energy of the TSS

      1             1 2        1
   T  m(r  r  )   mi i2  C0 (   )2  C1 (   )2 
          2  2 2
                                                                               (1)
      2             2 i0      2


where ρi  ri  r, i  0,1,2; q j   , , , l , r - generalized coordinates


 Potential energy
            2
              mi 3               m1l 2          c
 W      3  A  B  cos  
                            2
                                         cos 2   (l  l0 )2                   (2)
         i 0 ri 2r0              8r13            2

 Lagrange equations of the second kind

                              d L L
                                           Qj                                               D0 P, l  PD2
                              dt q j q j
                                  

where L    T W       - Lagrange function,        Qj   - nonpotential forces
                                                                                                                5
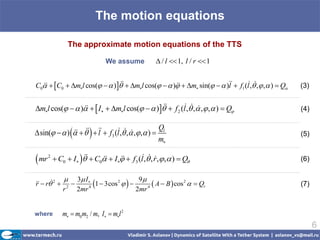
The motion equations

                The approximate motion equations of the TTS

                                We assume          / l  1, l / r  1


C0  C0  ml cos(   )  ml cos(   )  m sin(   )  f1 (l, , , )  Q
                                                              l                           (3)


ml cos(   )   I  ml cos(   )   f 2 (l, , , , )  Q
                                                                                           (4)


                 
                l                        Q
 sin(   )       f3 (l, , , , )  l
                                                m
                                                                                                 (5)


 mr   2
            C0  I   C0  I  f3 (l, , r , , )  Q
                                                                                         (6)

             3 I                      9
                    4 
r      
  r 2  2         1  3cos 2        4 
                                                A  B  cos 2   Qr                             (7)
           r    2mr                     2mr


where         m  m0 m2 / m, I  ml 2
                                                                                                       6
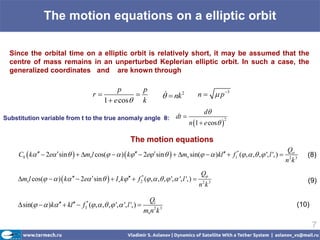
The motion equations on a elliptic orbit

  Since the orbital time on a elliptic orbit is relatively short, it may be assumed that the
  centre of mass remains in an unperturbed Keplerian elliptic orbit. In such a case, the
  generalized coordinates and are known through

                                                   p      p
                                        r                                    
                                                                                nk 2       n   p 3
                                              1  e cos k
                                                                                               d
Substitution variable from t to the true anomaly angle θ:                         dt 
                                                                                         n 1  e cos 
                                                                                                           2


                                                          The motion equations
                                                                                                                                  Q
     C0  k   2e  sin    ml cos(   )  k   2e  sin    m sin(   )kl   f1* ( , , , ', l ',)             (8)
                                                                                                                                 n2 k 3
                                                                                              Q
     ml cos(   )  k   2e  sin    I k   f 2* ( , , , ', ', l ',)                                                 (9)
                                                                                             n2 k 3

                                                                     Ql
      sin(   )k   kl   f3* ( , , , ', ', l ',)                                                                       (10)
                                                                   mn2 k 3

                                                                                                                                             7
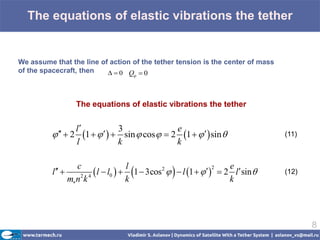
The equations of elastic vibrations the tether


We assume that the line of action of the tether tension is the center of mass
of the spacecraft, then   0 Q 0      


                     The equations of elastic vibrations the tether


                     l             3               e
             2      1      sin  cos   2 1     sin                (11)
                     l              k               k


                            l  l0   1  3cos    l 1  
                     c                l                                e
                      2 4 
          l                                                     2 l  sin 
                                                2                  2
                                                                                    (12)
                   mn k              k                                k


                                                                                           8
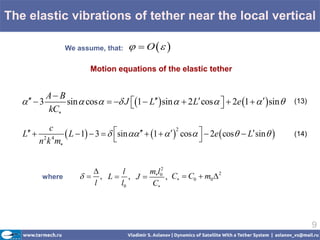
The elastic vibrations of tether near the local vertical

                    We assume, that:       O  

                            Motion equations of the elastic tether


              A B
      3        sin  cos   J 1  L  sin   2 L cos    2e 1     sin 
                                                                                              (13)
              kC
               c
   L               L  1  3   sin    1     cos   2e  cos  L sin  
                                                             2
                                                                                                (14)
           n2 k 4 m                                              


                                 l     ml02
            where          , L , J        , C  C0  m0 
                                                               2

                            l    l0      C


                                                                                                       9
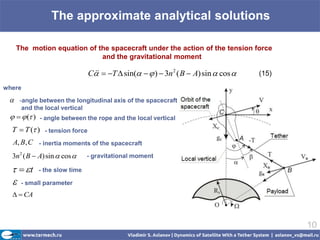
The approximate analytical solutions

     The motion equation of the spacecraft under the action of the tension force
                             and the gravitational moment

                               C  T  sin(   )  3n 2 ( B  A) sin  cos 
                                                                                 (15)

where

     -angle between the longitudinal axis of the spacecraft
       and the local vertical
    ( ) - angle between the rope and the local vertical
  T  T ( ) - tension force
  A, B, C - inertia moments of the spacecraft
  3n 2 ( B  A) sin  cos    - gravitational moment

    t    - the slow time

     - small parameter
    CA


                                                                                          10
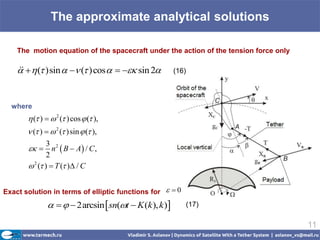
The approximate analytical solutions

    The motion equation of the spacecraft under the action of the tension force only

      ( )sin   ( ) cos    sin 2
                                                      (16)


  where
        ( )   2 ( ) cos  ( ),
        ( )   2 ( ) sin  ( ),
               3
         n 2  B  A / C ,
               2
        2 ( )  T ( ) / C


Exact solution in terms of elliptic functions for   0
                   2arcsin  sn(t  K (k ), k )      (17)

                                                                                       11
The approximate analytical solutions
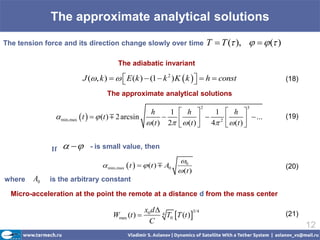
The tension force and its direction change slowly over time                     T  T ( ),    ( )

                                      The adiabatic invariant

                         J (, k )    E (k )  (1  k 2 ) K  k   h  const
                                                                                                       (18)

                                  The approximate analytical solutions
                                                                            2                 3
                                                    h      1     h         1        h 
                min,max  t    (t )  2 arcsin                         2
                                                                  (t )  4          (t )   ...    (19)
                                                    (t ) 2                               


              If        - is small value, then

                                                                0
                                 min,max  t    (t )  A0                                            (20)
                                                                 (t )
where   A0   is the arbitrary constant

  Micro-acceleration at the point the remote at a distance d from the mass center

                                                  x0 d  4
                                    Wmax (t )             T0 T (t )
                                                                      3/4
                                                                                                         (21)
                                                    C
                                                                                                                12
The approximate analytical solutions
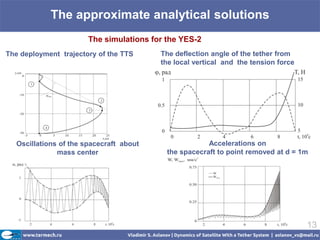
                        The simulations for the YES-2
The deployment trajectory of the TTS      The deflection angle of the tether from
                                          the local vertical and the tension force


   Oscillations of the spacecraft about                 Accelerations on
               mass center                  the spacecraft to point removed at d = 1m


                                                                                     13
The approximate analytical solutions

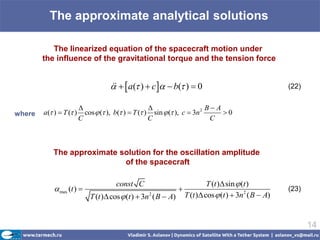
           The linearized equation of the spacecraft motion under
        the influence of the gravitational torque and the tension force


                                       a( )  c   b( )  0
                                                                                                      (22)


                                                                         B A
where   a( )  T ( )     cos  ( ), b( )  T ( ) sin  ( ), c  3n 2      0
                         C                           C                      C


            The approximate solution for the oscillation amplitude
                             of the spacecraft

                                       const C                               T (t ) sin  (t )
             max (t )                                                                                (23)
                             T (t ) cos  (t )  3n ( B  A)
                                                   2                T (t ) cos  (t )  3n2 ( B  A)


                                                                                                               14
Chaotic oscillations of the spacecraft
                   with a vertical tether
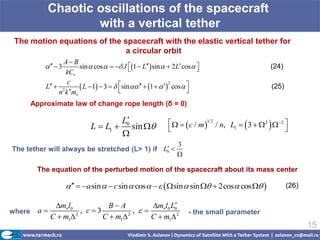
 The motion equations of the spacecraft with the elastic vertical tether for
                              a circular orbit
                A B
             3    sin  cos   J 1  L  sin   2 L cos 
                                                                                             (24)
                 kC
                  c
          L  2 4  L  1  3   sin    1     cos 
                                                            2
                                                                                               (25)
               n k m                                            
     Approximate law of change rope length (δ = 0)

                                     L                      c / m 1/2 / n, L1   3  2  2 
                             L  L1  0 sin                                                       
                                     
                                                              3
                                               
The tether will always be stretched (L> 1) if L0 
                                                              

       The equation of the perturbed motion of the spacecraft about its mass center

                        a sin   c sin  cos     sin  sin   2cos cos               (26)

             ml0           B A                 
                                           ml0 L0
where a              , c3           ,                         - the small parameter
            C  m1 2       C  m1 2      C  m1 2
                                                                                                             15
Chaotic oscillations of the spacecraft
                  with a vertical tether
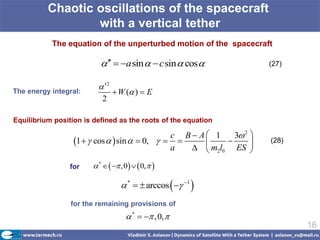
           The equation of the unperturbed motion of the spacecraft

                              a sin   c sin  cos            (27)


                           2
The energy integral:              W ( )  E
                           2

Equilibrium position is defined as the roots of the equation

                                               c B A 1    3 2 
                  1   cos   sin   0,                    (28)
                                               a    m2l0 ES 

                 for     *    ,0   0,  

                                    *   arccos   1 
                 for the remaining provisions of
                                      *   , 0, 
                                                                            16
Chaotic oscillations of the spacecraft
             with a vertical tether
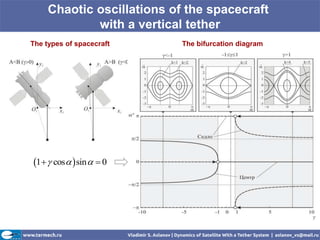
The types of spacecraft     The bifurcation diagram


1  cos  sin   0
Chaotic oscillations of the spacecraft
                 with a vertical tether
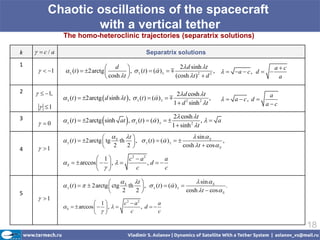
              The homo-heteroclinic trajectories (separatrix solutions)

k    c/a                                                          Separatrix solutions
1                                     d                                  2 d sinh t
       1      (t )  2arctg              ,   (t )  ( )   
                                                                                         ,   a  c , d   a  c
                                      cosh t                          (cosh t )  d
                                                                                   2    2
                                                                                                                 a

2     1,                                                                     2 d cosh t
                (t )  2arctg  d sinh t  ,   (t )  ( )  
                                                                                                ,     a  c, d 
                                                                                                                       a
                                                                               1  d 2 sinh 2 t                      ac
      1
                                                                              2 cosh t
3
      0                                          
                (t )  2arctg sinh at ,   (t )  ( )  
                                                       
                                                                              1  sinh 2 t
                                                                                            , a

                                         S        t                             sin  S
                (t )  2arctg  tg          th     ,   (t )  ( )   
                                                                                                ,
                                         2         2                         cosh t  cos  S
4     1
                              1        c2  a2       a
               S   arccos    ,           ,d 
                                         c          c

                                              S            t                           sin  S
                (t )    2arctg  ctg               th     ,   (t )  ( )  
                                                                                                       .
                                               2            2                       cosh t  cos  S
5
      1
                              1        c2  a2        a
               S   arccos    ,           , d 
                                         c           c

                                                                                                                            18
Chaotic oscillations of the spacecraft
                    with a vertical tether
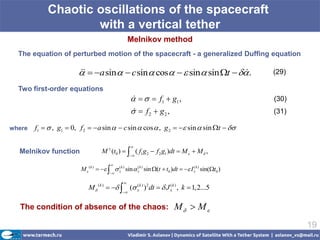
                                                   Melnikov method
  The equation of perturbed motion of the spacecraft - a generalized Duffing equation

                          a sin   c sin  cos   sin sin t   .
                                                                                                  (29)

  Two first-order equations
                                                       f1  g1 ,
                                                                                                    (30)
                                                     f2  g2 ,
                                                                                                    (31)

where   f1   , g1  0, f 2  a sin   c sin  cos  , g 2   sin  sin t  

                                                   
  Melnikov function                M  (t0 )   ( f1g2  f 2 g1 )dt  M   M  ,
                                                   

                                        
                         M  ( k )     k ) sin  k ) sin (t  t0 )dt   I k ) sin(t0 )
                                            (          (                            (
                                        

                                               
                            M  ( k )    ( k ) )2dt   J k ) , k  1,2...5
                                                (               (
                                              


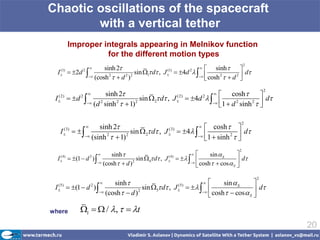
  The condition of absence of the chaos:                                 M  M
                                                                                                            19
Chaotic oscillations of the spacecraft
        with a vertical tether
               Improper integrals appearing in Melnikov function
                         for the different motion types
                             sinh 2                                      sinh
                                                                                             2
                                                                                
     I   (1)
               2d     2
                                         sin 1 d , J   4d 2  
                                                        (1)
                                                                                  2
                                                                                     d
                       (cosh   d )                               cosh   d
                                                                                  
                               2     2 2                                    2


                            sinh 2                                        cosh
                                                                                                     2
                                                                                 
 I   (2)
               d  2
                                         sin 2 d , J   4d 2  
                                                        (2)
                                                                                 2 
                                                                                      d
                      (d sinh   1)                               1  d sinh 
                                                                                   
                          2     2      2                                    2


                             sinh 2                                  cosh 
                                                                                             2
                                                                                   
         I   (3)
                                        sin  2 d , J   4  
                                                           (3)
                                                                                      d
                       (sinh 2   1) 2                           1  sinh 2  
                                                                                   
                                                                                         2
                                  sinh
                                                                          sin  S     
         (4)
                (1  d )       2
                                               sin 4 d , J     
                                                              (4)
                                                                                           d
                                                                       cosh   cos  
     I                      (cosh   d ) 2
                                                                                      S 


                                                                                                 2
                                  sinh
                                                                          sin  S     
     (5)
                (1  d )       2
                                               sin 5 d , J     
                                                              (5)
                                                                                           d
                                                                       cosh   cos  
 I                          (cosh   d ) 2
                                                                                      S 


where                 i   / ,   t
                                                                                                         20
Chaotic oscillations of the spacecraft
              with a vertical tether
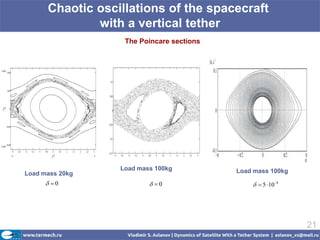
                   The Poincare sections


                  Load mass 100kg          Load mass 100kg
Load mass 20kg
       0                 0                   5  104


                                                              21
Chaotic oscillations of the spacecraft
                 with a vertical tether
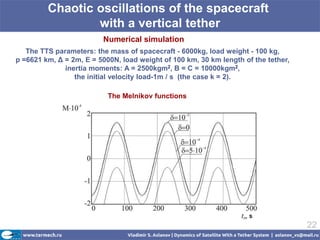
                         Numerical simulation
   The TTS parameters: the mass of spacecraft - 6000kg, load weight - 100 kg,
p =6621 km, Δ = 2m, E = 5000N, load weight of 100 km, 30 km length of the tether,
              inertia moments: A = 2500kgm2, B = C = 10000kgm2,
                 the initial velocity load-1m / s (the case k = 2).

                           The Melnikov functions


                                                                                    22
The main results were published
                       in the following papers
1. Aslanov V. S. and Ledkov A. S. Chaotic Oscillations of Spacecraft with an Elastic Radially
Oriented Tether, ISSN 00109525, Cosmic Research, 2012, Vol. 50, No. 2, pp. 188–198.
2. Aslanov V.S. Orbital oscillations of an elastic vertically-tethered satellite, Mechanics of Solids, Vol.
46, Number 5, 2011, pp. 657-668, DOI: 10.3103/S0025654411050013.
3. Aslanov V.S. The effect of the elasticity of an orbital tether system on the oscillations of a satellite -
Journal of Applied Mathematics and Mechanics 74 (2010) 416–424.
4. Aslanov V. Oscillations of a Spacecraft with a Vertical Elastic Tether, AIP Conference Proceedings
1220, CURRENT THEMES IN ENGINEERING SCIENCE 2009: Selected Presentations at the World
Congress on Engineering-2009, Published February 2010; ISBN 978-0-7354-0766-4, One Volume, pp.1-16.
5. Aslanov V. Oscillations of a Spacecraft with a Vertical Tether. Proceedings of the World Congress on
Engineering 2009 v. 2, pp. 1827-1831.
6. Aslanov V. The Oscillations of a Spacecraft under the Action of the Tether Tension. Moment and the
Gravitational Moment AIP (American Institute of Physics) Conf. Proc. September 1. 2008. v. 1048. 56-59
p. (ISBN: 978-0-7354-0576-9 )
7. Aslanov V. S. Chaotic behavior of the biharmonic dynamics system. International Journal of
Mathematics and Mathematical Sciences Volume 2009, Article ID 319179, 18 pages
doi:10.1155/2009/319179. 2009.
8. Aslanov V. S. The oscillations of a body with an orbital tethered system - Journal of Applied
Mathematics and Mechanics 71 (2007) 926–932.


                                                                                                          23