Presented by
Poly Ghosh
MPO,NILD
KOLKATA
 Over the past decade, options in prosthetic feet have expanded to more than 50
different models. Today, amputees have a wide array of feet to choose from,
designed for walking, dancing, cycling, golfing, swimming, snow skiing and
running.
 Heavier wood and steel materials have been replaced by lightweight plastics,
aerospace alloys and carbon-fiber composites.
 Much like the human foot , many of to day’s prosthetic feet can store and return
some of the energy generated during walking.
Ref: A publication of the amputee coalition of america in partnership with the U.S
Army Amputee patient care program
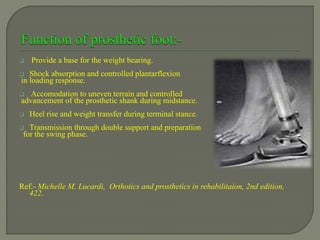
 Provide a base for the weight bearing.
 Shock absorption and controlled plantarflexion
in loading response.
 Accomodation to uneven terrain and controlled
advancement of the prosthetic shank during midstance.
 Heel rise and weight transfer during terminal stance.
 Transmission through double support and preparation
for the swing phase.
Ref:- Michelle M. Lucardi, Orthotics and prosthetics in rehabilitaion, 2nd edition,
422.
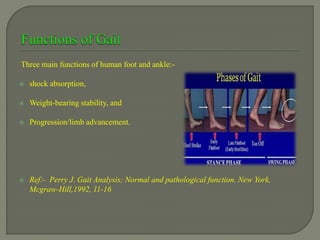
Three main functions of human foot and ankle:-
 shock absorption,
 Weight-bearing stability, and
 Progression/limb advancement.
 Ref:- Perry J. Gait Analysis; Normal and pathological function. New York,
Mcgraw-Hill,1992, 11-16
 The Prosthetic foot duplicates each biomechanical motion with a mechanical
substitute.
 This biomechanical motion dependent on the position of the components of the foot
as well as their motion and structure.
 An individual with an amputation has no physical connection between the
musculature of the residual limb and prosthetic foot, so prosthetic foot must
substitute the bony anatomy as well as loss of muscle action.
Ref:- Michelle M. Lucardi, Orthotics and prosthetics in rehabilitaion, 2nd edition,
422.
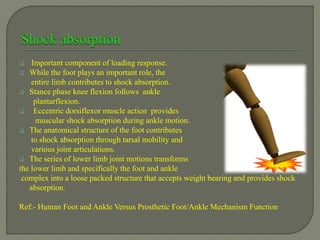
 Important component of loading response.
 While the foot plays an important role, the
entire limb contributes to shock absorption.
 Stance phase knee flexion follows ankle
plantarflexion.
 Eccentric dorsiflexor muscle action provides
muscular shock absorption during ankle motion.
 The anatomical structure of the foot contributes
to shock absorption through tarsal mobility and
various joint articulations.
 The series of lower limb joint motions transforms
the lower limb and specifically the foot and ankle
complex into a loose packed structure that accepts weight bearing and provides shock
absorption.
Ref:- Human Foot and Ankle Versus Prosthetic Foot/Ankle Mechanism Function
 Weightbearing Stability is essential as the
contralateral limb leaves the ground.
 Advancement of the loading force vector from the
hindfoot to the forefoot places an increasingly greater
demand on intertarsal and metatarsal alignment to alter
the foot and ankle complex from a loose packed and flexible
structure to close packed and rigid structure.
 Meanwhile, the medial longitudinal arch remains effective
at absorbing energy and adapting to uneven surfaces and
variable ground reaction forces.
 After midstance, a series of alignment changes occur between the hip, knee and tibia
that reverse from internal rotation to external rotation.
 The hindfoot and midfoot tarsals and forefoot metatarsals and phalanges gradually
transform the foot to a rigid lever structure capable of transferring loading,
providing stability and assisting in propulsion in late stance phase.
 Locking of the subtalar joint.
 From midstance to late stance and upon heel rise, tension creates upon the plantar
fascia to effectively shorten its length.
 “Windlass effect” transform the transverse tarsal joint into a closed packed position.
 The closed packed position creates a rigid lever system capable of transferring
loading across the foot at the push off phase of gait.
 The foot moves into the forefoot rocker from terminal
stance to pre-swing. Although the forefoot remains in contact
with the ground, the body is progressing through contralateral
swing in preparation for ipsilateral swing.
 At the end of stance phase, forefoot dorsiflexion
reaches a peak, maximizing the windlass effect.
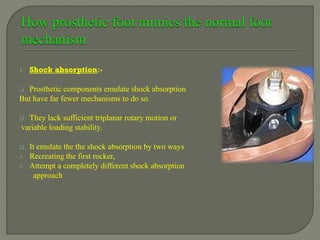
1. Shock absorption:-
 Prosthetic components emulate shock absorption
But have far fewer mechanisms to do so.
 They lack sufficient triplanar rotary motion or
variable loading stability.
 It emulate the the shock absorption by two ways
A. Recreating the first rocker,
B. Attempt a completely different shock absorption
approach
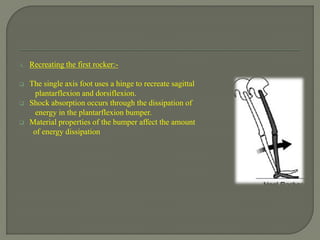
A. Recreating the first rocker:-
 The single axis foot uses a hinge to recreate sagittal
plantarflexion and dorsiflexion.
 Shock absorption occurs through the dissipation of
energy in the plantarflexion bumper.
 Material properties of the bumper affect the amount
of energy dissipation
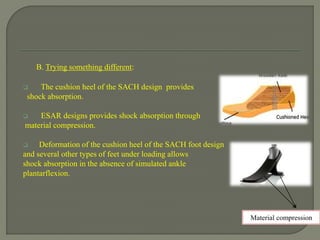
B. Trying something different:
 The cushion heel of the SACH design provides
shock absorption.
 ESAR designs provides shock absorption through
material compression.
 Deformation of the cushion heel of the SACH foot design
and several other types of feet under loading allows
shock absorption in the absence of simulated ankle
plantarflexion.
Material compression
 Prosthetic foot/ankle mechanism requires softness at initial stance and the stiffness
required at terminal stance.
 A prosthetic foot/ankle mechanism with flexible keel and forefoot will encounter
knee instability due to deformation of the prosthetic forefoot during terminal stance.
 One disadvantage in foot/ankle mechanism designs with a cushion type heel is the
prolonged "heel-only" contact. This produces an unstable external knee flexion
moment until the forefoot makes contact.
 EMG studies reveal prolonged co-contraction of hamstrings and quadriceps muscle
groups to maintain stability.
 Knee instability associated with prolonged loading upon the heel may also result in
more falls when persons with limb loss walk on low-friction surfaces such as wet
tile or ice.
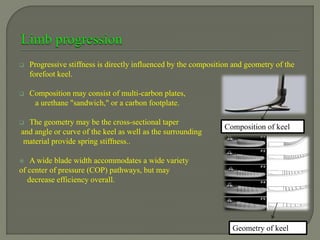
 Progressive stiffness is directly influenced by the composition and geometry of the
forefoot keel.
 Composition may consist of multi-carbon plates,
a urethane "sandwich," or a carbon footplate.
 The geometry may be the cross-sectional taper
and angle or curve of the keel as well as the surrounding
material provide spring stiffness..
 A wide blade width accommodates a wide variety
of center of pressure (COP) pathways, but may
decrease efficiency overall.
Geometry of keel
Composition of keel
 Categories of the prosthetic foot are based on the combination of functional tasks
that they are designed to simulate.
 Classification:-
1. Nonarticulating feet
2. Articulating design (Single axis, multi-axial feet)
3. Prosthetic feet with elastic keel
4. Dyanamic response or energy storing feet
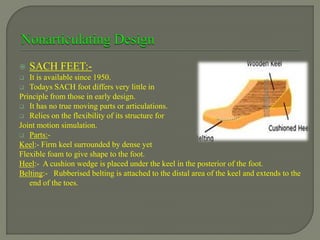
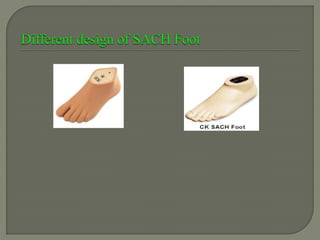
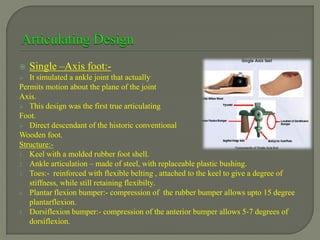
 SACH FEET:-
 It is available since 1950.
 Todays SACH foot differs very little in
Principle from those in early design.
 It has no true moving parts or articulations.
 Relies on the flexibility of its structure for
Joint motion simulation.
 Parts:-
Keel:- Firm keel surrounded by dense yet
Flexible foam to give shape to the foot.
Heel:- A cushion wedge is placed under the keel in the posterior of the foot.
Belting:- Rubberised belting is attached to the distal area of the keel and extends to the
end of the toes.
 This belting simulates to flexors and assist in giving a slight resistance to MP
extension during preswing, thus preventing a feeling of dropping off of the toe
during this phase of gait.
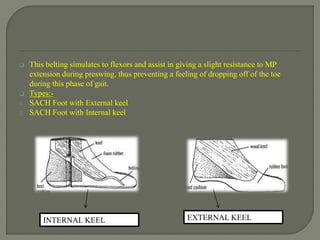
 Types:-
1. SACH Foot with External keel
2. SACH Foot with Internal keel
INTERNAL KEEL EXTERNAL KEEL
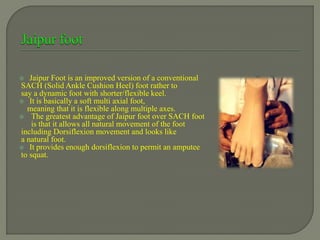
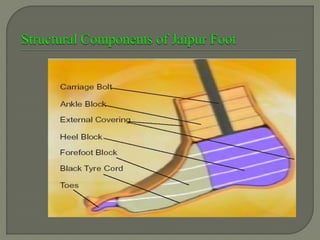
 Jaipur Foot is an improved version of a conventional
SACH (Solid Ankle Cushion Heel) foot rather to
say a dynamic foot with shorter/flexible keel.
 It is basically a soft multi axial foot,
meaning that it is flexible along multiple axes.
 The greatest advantage of Jaipur foot over SACH foot
is that it allows all natural movement of the foot
including Dorsiflexion movement and looks like
a natural foot.
 It provides enough dorsiflexion to permit an amputee
to squat.
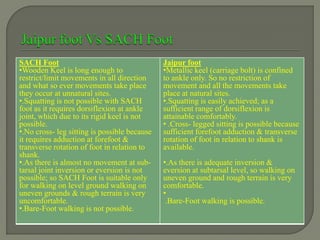
SACH Foot
•Wooden Keel is long enough to
restrict/limit movements in all direction
and what so ever movements take place
they occur at unnatural sites.
•.Squatting is not possible with SACH
foot as it requires dorsiflexion at ankle
joint, which due to its rigid keel is not
possible.
•.No cross- leg sitting is possible because
it requires adduction at forefoot &
transverse rotation of foot in relation to
shank.
•.As there is almost no movement at sub-
tarsal joint inversion or eversion is not
possible; so SACH Foot is suitable only
for walking on level ground walking on
uneven grounds & rough terrain is very
uncomfortable.
•.Bare-Foot walking is not possible.
Jaipur foot
•Metallic keel (carriage bolt) is confined
to ankle only. So no restriction of
movement and all the movements take
place at natural sites.
•.Squatting is easily achieved; as a
sufficient range of dorsiflexion is
attainable comfortably.
• .Cross- legged sitting is possible because
sufficient forefoot adduction & transverse
rotation of foot in relation to shank is
available.
•.As there is adequate inversion &
eversion at subtarsal level, so walking on
uneven ground and rough terrain is very
comfortable.
•
.Bare-Foot walking is possible.
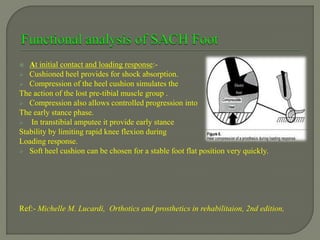
 At initial contact and loading response:-
 Cushioned heel provides for shock absorption.
 Compression of the heel cushion simulates the
The action of the lost pre-tibial muscle group .
 Compression also allows controlled progression into
The early stance phase.
 In transtibial amputee it provide early stance
Stability by limiting rapid knee flexion during
Loading response.
 Soft heel cushion can be chosen for a stable foot flat position very quickly.
Ref:- Michelle M. Lucardi, Orthotics and prosthetics in rehabilitaion, 2nd edition,
 Midstance:-
 SACH foot has no true inversion and eversion motion to accommodate uneven
terrain.
 The rubber structure may aid in, but i.e very negligient amount.
 Simulation of the ankle rocker is controlled through the keel of the foot.
 The rigid keel offers resistance to tibial advancement until the weight line is past
the toe break of the foot.
 Terminal stance:-
 Heel rise during toe rocker and progression are function of the length of the keel.
 Some SACH foot use various keel lengths or densities but mostly use keel length
corresponds to length of the foot.
 In late stance .the prosthetic foot stable and resists rapid heel rise until the weight
line passes the toe break, where the keel ends.
 When weight line reached at the end of the keel toe dorsiflexion begins.
 If keel is too short, early heel rise and rapid knee flexion occurs.
 If keel is too long, heel rise and knee extension moment delayed.
 Toe break simulates dorsiflexion.
 Toe dorsiflexion is controlled by belting, so the tibial progression smoothly.
 Dorsiflexed toe offer little weight bearing support.
 It also depends on alignment with socket and foot,.
 Flexibility of the belting material adds a small elastic motin to help in knee flexion
as the prosthetic foot moves towards the preswing phase.
 Indication:-
Prosthetic users at the level of household and limited community ambulation.
 Contraindication:-
In high level activities and sports or if the user must traverse uneven terrain.
 Advantages:-
1. Extreme durable.
2. Requires very little maintenance throughout the life of the foot.
3. It has wide variety of heel heights.
4. Excellent shock absorption characteristic.
5. Often recommended for use in temporary or preparatory prosthesis.
6. Light wt.
7. Low cost.
 Disadvantages:-
1. Inherent lack of flexibility.
2. Inability to accommodate uneven terrain.
3. Proper alignment is very difficult because of lack of movable artculations.
4. Its design and construction allows optimal performance during relaxed walking
cadence and in a single alignment configuraton.
 Sten foot:- Stored energy foot
 Dual articulated wooden keel.
 Tarsometarsal & metatarsophalangeal keel
articulation Provide smoother roll over.
 cushioned heel provide shock absorption.
 Externally it uses kinsgley foot mold & rubber.
 Heavier than SACH foot.
 Expensive than SACH foot.
 In higher level amputee knee buckle occurs.
Rubber plugs
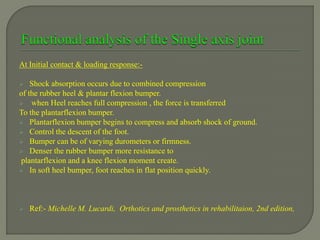
 Single –Axis foot:-
 It simulated a ankle joint that actually
Permits motion about the plane of the joint
Axis.
 This design was the first true articulating
Foot.
 Direct descendant of the historic conventional
Wooden foot.
Structure:-
1. Keel with a molded rubber foot shell.
2. Ankle articulation – made of steel, with replaceable plastic bushing.
3. Toes:- reinforced with flexible belting , attached to the keel to give a degree of
stiffness, while still retaining flexibilty.
4. Plantar flexion bumper:- compression of the rubber bumper allows upto 15 degree
plantarflexion.
5. Dorsiflexion bumper:- compression of the anterior bumper allows 5-7 degrees of
dorsiflexion.
At Initial contact & loading response:-
 Shock absorption occurs due to combined compression
of the rubber heel & plantar flexion bumper.
 when Heel reaches full compression , the force is transferred
To the plantarflexion bumper.
 Plantarflexion bumper begins to compress and absorb shock of ground.
 Control the descent of the foot.
 Bumper can be of varying durometers or firmness.
 Denser the rubber bumper more resistance to
plantarflexion and a knee flexion moment create.
 In soft heel bumper, foot reaches in flat position quickly.
 Ref:- Michelle M. Lucardi, Orthotics and prosthetics in rehabilitaion, 2nd edition,
 At midstance:-
 Articulation allows only sagittal plane motion.
 Accomodation to uneven terrain.
 No true coronal plane movement.
 Inversion/eversion motion is due to inherent flexibility within the rubber portion of
the foot and toes.
 Combination of the dorsiflexion bumper and solid keel controls the advancement of
the prosthesis tibial shank during midstance.
 After full dorsiflexion movement keel acts as a rocker to continue the tibial shank
progression.
 At Terminal stance & preswing:
 Heel rise is determined by dorsiflexion bumper or stop.
 Force is transferred to the foot, heel rise is intiated once the bumper is fully
engaged.
 The length of the keel in the foot also contributes to the control of heel rise.
 Once the end point of ankle dorsiflexion is reached, the distal portion of the keel
acts as a rocker.
 When the force is transferred to the end of the keel, toe dorsiflexion begins.
 At the initiation of the preswing functions is same as SACH foot.
 Indications:-
 Transtibial amputee with adequate knee extensors.
 Nonremrdiable strength impairment
 Short residual limb.
 Transfemoral amputee with good hip extensors.
 Contraindication:-
 Patient with poor aerobic capacity.
 Strength impairment.
 Advantages:-
1. Able to reach a stable foot –flat position quickly in the early stance. This
advantageous for activities that have an impact on knee stability.
2. Reduces the need for strong knee extension in loading response.
3. Reduces the knee flexion moment during loading response.
4. Capability of changing the durometers of the bumper to suit the needs and activity
level of the users.
 Disadvantages:-
1. Increased wt.
2. Needs maintenance.
3. Increased energy demand.
4. occasional service for normal wear and tear.
5. Bushing in the joint needs to be replaced.
6. With repeated loading bumper can fatigue over time.
 This foot operates in a similar manner to the single-axis foot, using various
combinations of rubber bumpers.
 Allows coronal, transverse and sagittal motion.
 Stability is found at only at the extremes of each plane of motion.
 These foot/ankle mechanisms can be a simple split-keel variety, a carbon plate
urethane overmolded sandwich, a hindfoot articulation or a combination of these
designs.
 Available in variety of styles.
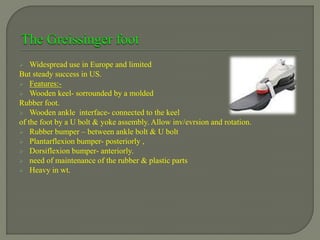
1. The Greissinger foot (Ottobock industries)
2. Multiflex ankle-foot(Endolite America)
 Widespread use in Europe and limited
But steady success in US.
 Features:-
 Wooden keel- sorrounded by a molded
Rubber foot.
 Wooden ankle interface- connected to the keel
of the foot by a U bolt & yoke assembly. Allow inv/evrsion and rotation.
 Rubber bumper – between ankle bolt & U bolt
 Plantarflexion bumper- posteriorly ,
 Dorsiflexion bumper- anteriorly.
 need of maintenance of the rubber & plastic parts
 Heavy in wt.
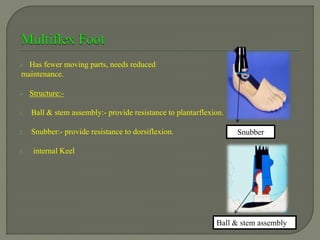
 Has fewer moving parts, needs reduced
maintenance.
 Structure:-
1. Ball & stem assembly:- provide resistance to plantarflexion.
2. Snubber:- provide resistance to dorsiflexion.
3. internal Keel
Ball & stem assembly
Snubber
 At initial contact & loading response:-
 Shock absorption is provided by the compression
rubber ball & stem.
 During shock absorption compression O ring occurs
between ankle & foot.
 As weight is applied compression of the rubber ball
provide controlled progression to midstance.
 Plantar flexion resistance can be adjusted by changing
the bumper or O ring.
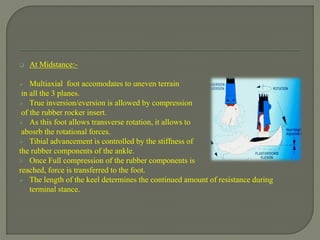
 At Midstance:-
 Multiaxial foot accomodates to uneven terrain
in all the 3 planes.
 True inversion/eversion is allowed by compression
of the rubber rocker insert.
 As this foot allows transverse rotation, it allows to
abosrb the rotational forces.
 Tibial advancement is controlled by the stiffness of
the rubber components of the ankle.
 Once Full compression of the rubber components is
reached, force is transferred to the foot.
 The length of the keel determines the continued amount of resistance during
terminal stance.
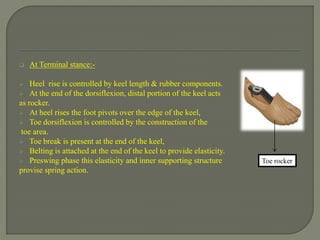
 At Terminal stance:-
 Heel rise is controlled by keel length & rubber components.
 At the end of the dorsiflexion, distal portion of the keel acts
as rocker.
 At heel rises the foot pivots over the edge of the keel,
 Toe dorsiflexion is controlled by the construction of the
toe area.
 Toe break is present at the end of the keel,
 Belting is attached at the end of the keel to provide elasticity.
 Preswing phase this elasticity and inner supporting structure
provise spring action.
Toe rocker
 Indications:-
1. Those with mechanical instability of their anatomical knee
2. Poor postural control.
3. Vulnerable skin or fixed adhesion along the incision line of residual limb
 Contraindications:-
1. Muscle weakness
2. An individual unwilling to schedule regular maintenance.
 Advantages:-
1. Accommodate uneven terrain in more than one plane.
2. Useful for reducing torque forces on the residual limb during stance.
3. The density of the rubber bumpers can be changed for accomodation to user’s
weight & activity level.
 Disadvantage:-
1. Motion is allowed in all 3 planes, provides less static stability.
2. Muscle weakness people may not feel stable.
3. Heavier than non-articulating, elastic keel or dyanamic response foot.
4. Needs regular maintenance for moving parts.
5. Bushing and bumpers may wear and tear with use.
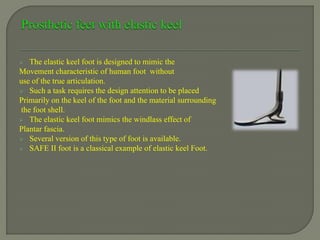
 The elastic keel foot is designed to mimic the
Movement characteristic of human foot without
use of the true articulation.
 Such a task requires the design attention to be placed
Primarily on the keel of the foot and the material surrounding
the foot shell.
 The elastic keel foot mimics the windlass effect of
Plantar fascia.
 Several version of this type of foot is available.
 SAFE II foot is a classical example of elastic keel Foot.
 SAFE II FOOT:-
 Solid attachment flexible endoskeleton foot.
Structure:-
1. Cushioned heel
2. Keel- two parts
3. Short plantar band
4. Long plantar band
5. Toe break Heel
Proximal keel
Distal keel
Plantar band
Toe break
 At initial contact & loading response:-
 Heel cushion and relative movement of the rigid block within the foot shell
provides shock absorption.
 In some foot keel flexibility also provides shock absorption.
o At midstance;-
o The differences in this feet become apparent during the transitions from early stance
through midstance to terminal stance.
 Inversion/eversion is simulted by flexilbility of the elastic keel.
 Accomodation to terrain occurs between keel & its sorrounding dtructure.
 Tibial advancement is controlled by the plantar band.
 As the tibia advances, the keel begins to bend & foot start to dorsiflex.
 The plantar band begins to tighten, controlling the rate that the keel bends.
 Other foot this occurs due to flexible keel.
 Most elastic keel feet have limited ability of rotation.
 Rotation occurs due to movement of flexible keel within the rubber housing.
o Terminal stance:-
 Heel rise is controlled by the stiffness of the keel.
 Tibial advancement occur and weight transferred onto forefoot.
 Keel extends all the way into the toe area.
 No rocker effect.
 Elastic keel feet eliminates the need for a rocker effect and provide a smoother roll-
over.
 SAFE II foot has additional control during dorsiflexion & heel rise as tension is
applied to plantar bands.
 Bands allows gradual stiffening of the forefoot to create a semirigid lever during
terminal stance.
 Other foot rely on flexibility of keel.
 Elastic keel compressed.
 In preswing a sense of energy returns is there.
 Ref:- Michelle M. Lucardi, Orthotics and prosthetics in rehabilitaion, 2nd edition,
 Indications:-
 Individual with a moderate need for accomodation to uneven terrain.
 Alternative for the prosthetics user who would benefit from the multiaxial foot but
does not want the maintenance or weight characteristic.
 Contraindications:-
o Extremely active patient who prefer a stiffer keel.
 Advantages:-
1. Provide a very smooth gait pattern.
2. Stair climbing or descent and incline negotiation is easy.
3. Range of motion and torque absorption is possible.
 Disadvantages:-
Spongy feel may be disliked for those who needs greater sense of stability.
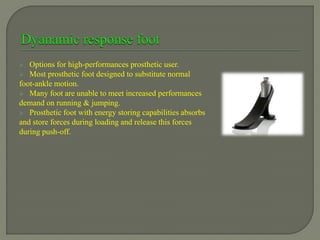
 Options for high-performances prosthetic user.
 Most prosthetic foot designed to substitute normal
foot-ankle motion.
 Many foot are unable to meet increased performances
demand on running & jumping.
 Prosthetic foot with energy storing capabilities absorbs
and store forces during loading and release this forces
during push-off.
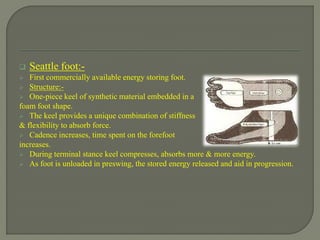
 Seattle foot:-
 First commercially available energy storing foot.
 Structure:-
 One-piece keel of synthetic material embedded in a
foam foot shape.
 The keel provides a unique combination of stiffness
& flexibility to absorb force.
 Cadence increases, time spent on the forefoot
increases.
 During terminal stance keel compresses, absorbs more & more energy.
 As foot is unloaded in preswing, the stored energy released and aid in progression.
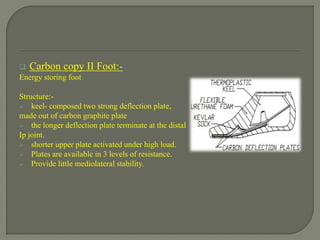
 Carbon copy II Foot:-
Energy storing foot
Structure:-
 keel- composed two strong deflection plate,
made out of carbon graphite plate
 the longer deflection plate terminate at the distal
Ip joint.
 shorter upper plate activated under high load.
 Plates are available in 3 levels of resistance.
 Provide little mediolateral stability.
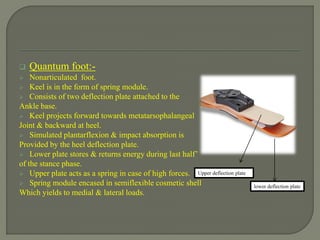
 Quantum foot:-
 Nonarticulated foot.
 Keel is in the form of spring module.
 Consists of two deflection plate attached to the
Ankle base.
 Keel projects forward towards metatarsophalangeal
Joint & backward at heel.
 Simulated plantarflexion & impact absorption is
Provided by the heel deflection plate.
 Lower plate stores & returns energy during last half’
of the stance phase.
 Upper plate acts as a spring in case of high forces.
 Spring module encased in semiflexible cosmetic shell
Which yields to medial & lateral loads.
Upper deflection plate
lower deflection plate
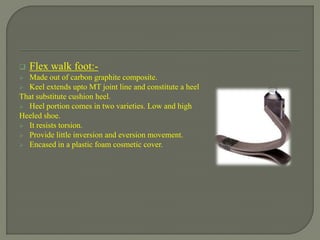
 Flex walk foot:-
 Made out of carbon graphite composite.
 Keel extends upto MT joint line and constitute a heel
That substitute cushion heel.
 Heel portion comes in two varieties. Low and high
Heeled shoe.
 It resists torsion.
 Provide little inversion and eversion movement.
 Encased in a plastic foam cosmetic cover.
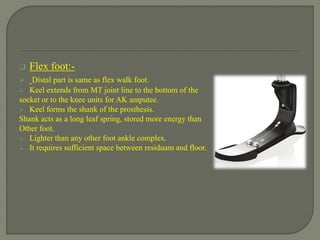
 Flex foot:-
 Distal part is same as flex walk foot.
 Keel extends from MT joint line to the bottom of the
socket or to the knee units for AK amputee.
 Keel forms the shank of the prosthesis.
Shank acts as a long leaf spring, stored more energy than
Other foot.
 Lighter than any other foot ankle complex.
 It requires sufficient space between residuam and floor.
 Indications:-
1. High demand activities .
2. When maximum late stance dorsiflexion is desired.
3. When frequent changes in cadence or velocity is necessary or when walking on
inclines.
4. Long arc of dorsiflexion protect the sound limb against execessive vertical force.
 Contraindication:-
Amputee with relaxed gait and household ambulation.
 Advantages:-
1. Most user able to walk with less difficulty and more energy efficiency over a range
of grades & speeds.
2. Wide variety of stiffness available acc. To the need of the patient.
 Disadvantages:-
1. Designed to deform under loading condition, if not sufficient force is there, it
become very stiff and unaccomodating.
2. Cost is high.
 At initial contact & loading response:-
 Shock absorption during early stance is comparable to the other classes.
 Cushion heel compresses to absorb the shock.
 Control of plantarflexion is also affected by the stiffness in the heel.
o At midstnace:-
 Do not have significant ground accomodation
 Stiff elastic keel feet.
 Rubber and foam shell minimal accomdation of terrain.
 No true inversion/eversion .
 In split toe allows some degree of coronal plane motion.
o At terminal stance:-
 Significant difference in tibial advancement.
 As cadence increases to running , extra stiffness is required during midstance into
terminal stance.
 Tibial advancement is controlled by stiffness of keel.
 The shaft advances, keel deflects, absorbs forces generated during deflection and resists
rapid advancement.
o Progression of heel rise is related to stiffness of the keel.
o As the shaft continues to advance, the keel continues to deflect and the foot
dorsiflexes as weight progresses onto the forefoot.
o The keel extended upto distal end of the foot.
o No rocker action.
o Extended keel provide necessary support.
o In high loading activity progression onto the forefoot occurs through a smooth arc of
dorsiflexion as the keel continues to deform under the increasing load throughout
this phase.
o Keel deflection and dorsiflexion are now at their maximum points.
o Stiff yet flexible keel has allowed maximal dorsiflexion without sacrificing support
to the amputated side, the runner is allowed a longer stride length.
o As unloaded keel begins to decomoress to return to its original shape, creating a
spring action.
 Indication:-
1. When late stance dorsiflexion is desired.
2. When frequent changes in cadence or velocity is necessary.
3. When walking on inclines.
 Contraindication:-
 For users unable to generate enough forces to deform.
 Advantages:-
Walk with less difficulty and more energy efficiency over a range grades and speeds.
 Disadvantages:-
 Cost is high.
 Stiff if enough forces is not applied.
 Hybridizing the properties of different classes, primarily by combining dynamic
response feet with multi-axis attributes.
 The traditional classification system has become outdated .
 Proposed subsets could include:
1. Forefoot Keel
2. Heel Lever
3. Hindfoot Roller
4. Flexing Strut
5. Forefoot Inversion/Eversion
6. Multiaxis Hindfoot
7. Integrated Shock
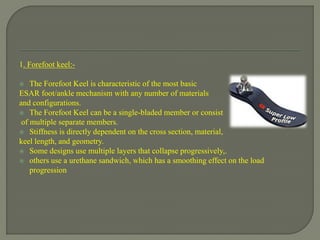
1. Forefoot keel:-
 The Forefoot Keel is characteristic of the most basic
ESAR foot/ankle mechanism with any number of materials
and configurations.
 The Forefoot Keel can be a single-bladed member or consist
of multiple separate members.
 Stiffness is directly dependent on the cross section, material,
keel length, and geometry.
 Some designs use multiple layers that collapse progressively,.
 others use a urethane sandwich, which has a smoothing effect on the load
progression
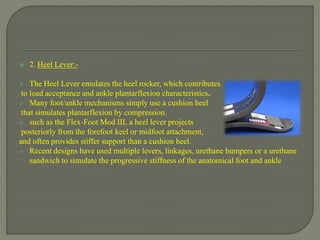
 2. Heel Lever:-
 The Heel Lever emulates the heel rocker, which contributes
to load acceptance and ankle plantarflexion characteristics.
 Many foot/ankle mechanisms simply use a cushion heel
that simulates plantarflexion by compression.
 such as the Flex-Foot Mod III, a heel lever projects
posteriorly from the forefoot keel or midfoot attachment,
and often provides stiffer support than a cushion heel.
 Recent designs have used multiple levers, linkages, urethane bumpers or a urethane
sandwich to simulate the progressive stiffness of the anatomical foot and ankle
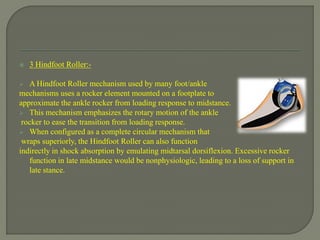
 3 Hindfoot Roller:-
 A Hindfoot Roller mechanism used by many foot/ankle
mechanisms uses a rocker element mounted on a footplate to
approximate the ankle rocker from loading response to midstance.
 This mechanism emphasizes the rotary motion of the ankle
rocker to ease the transition from loading response.
 When configured as a complete circular mechanism that
wraps superiorly, the Hindfoot Roller can also function
indirectly in shock absorption by emulating midtarsal dorsiflexion. Excessive rocker
function in late midstance would be nonphysiologic, leading to a loss of support in
late stance.
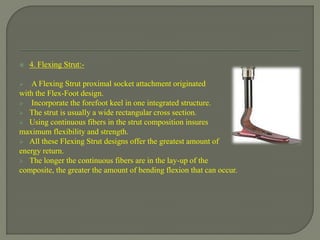
 4. Flexing Strut:-
 A Flexing Strut proximal socket attachment originated
with the Flex-Foot design.
 Incorporate the forefoot keel in one integrated structure.
 The strut is usually a wide rectangular cross section.
 Using continuous fibers in the strut composition insures
maximum flexibility and strength.
 All these Flexing Strut designs offer the greatest amount of
energy return.
 The longer the continuous fibers are in the lay-up of the
composite, the greater the amount of bending flexion that can occur.
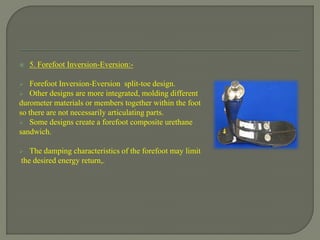
 5. Forefoot Inversion-Eversion:-
 Forefoot Inversion-Eversion split-toe design.
 Other designs are more integrated, molding different
durometer materials or members together within the foot
so there are not necessarily articulating parts.
 Some designs create a forefoot composite urethane
sandwich.
 The damping characteristics of the forefoot may limit
the desired energy return,.
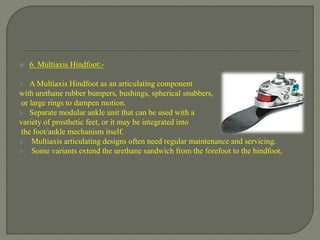
 6. Multiaxis Hindfoot:-
 A Multiaxis Hindfoot as an articulating component
with urethane rubber bumpers, bushings, spherical snubbers,
or large rings to dampen motion.
 Separate modular ankle unit that can be used with a
variety of prosthetic feet, or it may be integrated into
the foot/ankle mechanism itself.
 Multiaxis articulating designs often need regular maintenance and servicing.
 Some variants extend the urethane sandwich from the forefoot to the hindfoot,
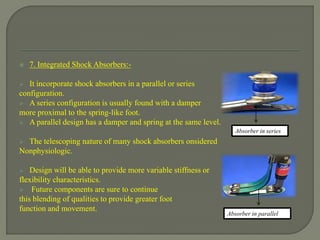
 7. Integrated Shock Absorbers:-
 It incorporate shock absorbers in a parallel or series
configuration.
 A series configuration is usually found with a damper
more proximal to the spring-like foot.
 A parallel design has a damper and spring at the same level.
 The telescoping nature of many shock absorbers onsidered
Nonphysiologic.
 Design will be able to provide more variable stiffness or
flexibility characteristics.
 Future components are sure to continue
this blending of qualities to provide greater foot
function and movement.
Absorber in series
Absorber in parallel
 Heel height and type of shoes.
 Standard prosthetic heel height is ¾ inch.
 Foots ability to resist moisture.
 Users activity level and body weight.
 Vocational and recreational activity must be concluded.
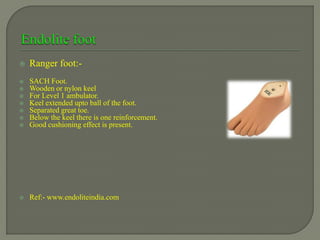
 Ranger foot:-
 SACH Foot.
 Wooden or nylon keel
 For Level 1 ambulator.
 Keel extended upto ball of the foot.
 Separated great toe.
 Below the keel there is one reinforcement.
 Good cushioning effect is present.
 Ref:- www.endoliteindia.com
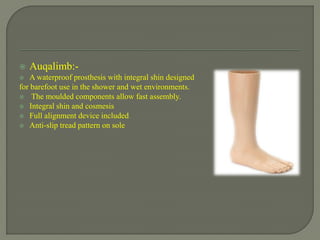
 Auqalimb:-
 A waterproof prosthesis with integral shin designed
for barefoot use in the shower and wet environments.
 The moulded components allow fast assembly.
 Integral shin and cosmesis
 Full alignment device included
 Anti-slip tread pattern on sole
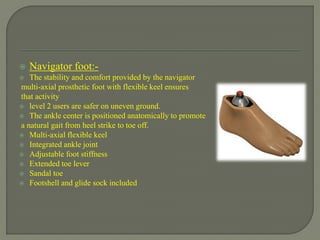
 Navigator foot:-
 The stability and comfort provided by the navigator
multi-axial prosthetic foot with flexible keel ensures
that activity
 level 2 users are safer on uneven ground.
 The ankle center is positioned anatomically to promote
a natural gait from heel strike to toe off.
 Multi-axial flexible keel
 Integrated ankle joint
 Adjustable foot stiffness
 Extended toe lever
 Sandal toe
 Footshell and glide sock included
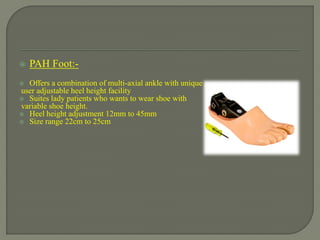
 PAH Foot:-
 Offers a combination of multi-axial ankle with unique ,
user adjustable heel height facility
 Suites lady patients who wants to wear shoe with
variable shoe height.
 Heel height adjustment 12mm to 45mm
 Size range 22cm to 25cm
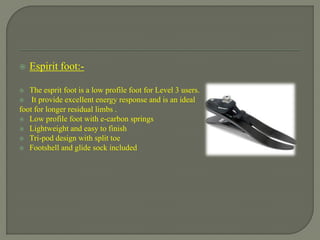
 Espirit foot:-
 The esprit foot is a low profile foot for Level 3 users.
 It provide excellent energy response and is an ideal
foot for longer residual limbs .
 Low profile foot with e-carbon springs
 Lightweight and easy to finish
 Tri-pod design with split toe
 Footshell and glide sock included
 Epirus foot:-
 The Epirus foot is a low profile multi-axial
prosthetic foot for Level 3 activity.
 Multi-axial ankle motion with tri-pod stability
 Independent e-carbon foot springs
 Ground compliance and energy efficient response
 Foot shell with cosmetic attachment plate
 Footshell and glide sock included

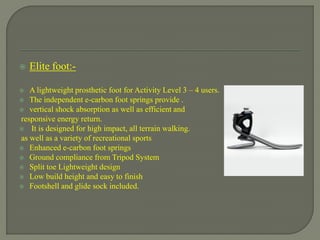
 Elite foot:-
 A lightweight prosthetic foot for Activity Level 3 – 4 users.
 The independent e-carbon foot springs provide .
 vertical shock absorption as well as efficient and
responsive energy return.
 It is designed for high impact, all terrain walking.
as well as a variety of recreational sports
 Enhanced e-carbon foot springs
 Ground compliance from Tripod System
 Split toe Lightweight design
 Low build height and easy to finish
 Footshell and glide sock included.
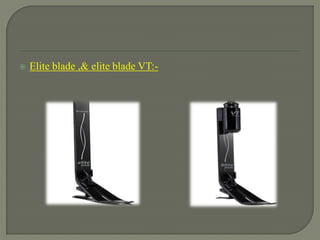
 Elite blade ,& elite blade VT:-
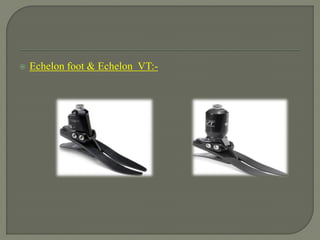
 Echelon foot & Echelon VT:-
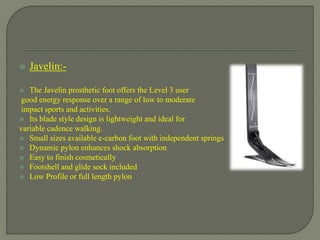
 Javelin:-
 The Javelin prosthetic foot offers the Level 3 user
good energy response over a range of low to moderate
impact sports and activities.
 Its blade style design is lightweight and ideal for
variable cadence walking.
 Small sizes available e-carbon foot with independent springs
 Dynamic pylon enhances shock absorption
 Easy to finish cosmetically
 Footshell and glide sock included
 Low Profile or full length pylon
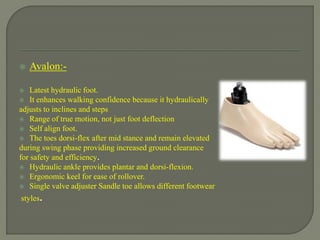
 Avalon:-
 Latest hydraulic foot.
 It enhances walking confidence because it hydraulically
adjusts to inclines and steps
 Range of true motion, not just foot deflection
 Self align foot.
 The toes dorsi-flex after mid stance and remain elevated
during swing phase providing increased ground clearance
for safety and efficiency.
 Hydraulic ankle provides plantar and dorsi-flexion.
 Ergonomic keel for ease of rollover.
 Single valve adjuster Sandle toe allows different footwear
styles.
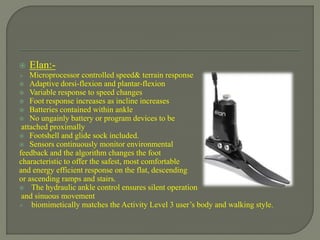
 Elan:-
 Microprocessor controlled speed& terrain response
 Adaptive dorsi-flexion and plantar-flexion
 Variable response to speed changes
 Foot response increases as incline increases
 Batteries contained within ankle
 No ungainly battery or program devices to be
attached proximally
 Footshell and glide sock included.
 Sensors continuously monitor environmental
feedback and the algorithm changes the foot
characteristic to offer the safest, most comfortable
and energy efficient response on the flat, descending
or ascending ramps and stairs.
 The hydraulic ankle control ensures silent operation
and sinuous movement
 biomimetically matches the Activity Level 3 user’s body and walking style.
1. Carbon Feet
2. Dynamic Feet
3. Greissinger Plus Foot
4. Adjust Foot
5. SACH+ feet
6. Single-Axis Feet
7. Light Cosmetic Feet
8. Chopart Foot Plate
9. Sports Feet
Ref:- www.ottobock.com
Carbon foot:-
1. Axiton foot
2. Trias foot
3. Axiton DP foot
4. Advantage DP2 Foot
5. C-Walk
6. Lo rider foot
7. Triton
8. Springlite
9. prosymes
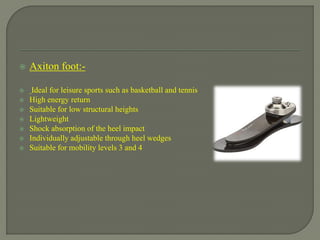
 Axiton foot:-
 Ideal for leisure sports such as basketball and tennis
 High energy return
 Suitable for low structural heights
 Lightweight
 Shock absorption of the heel impact
 Individually adjustable through heel wedges
 Suitable for mobility levels 3 and 4
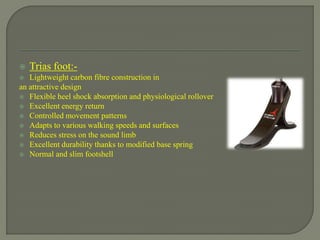
 Trias foot:-
 Lightweight carbon fibre construction in
an attractive design
 Flexible heel shock absorption and physiological rollover
 Excellent energy return
 Controlled movement patterns
 Adapts to various walking speeds and surfaces
 Reduces stress on the sound limb
 Excellent durability thanks to modified base spring
 Normal and slim footshell
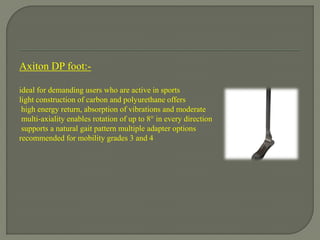
Axiton DP foot:-
ideal for demanding users who are active in sports
light construction of carbon and polyurethane offers
high energy return, absorption of vibrations and moderate
multi-axiality enables rotation of up to 8° in every direction
supports a natural gait pattern multiple adapter options
recommended for mobility grades 3 and 4
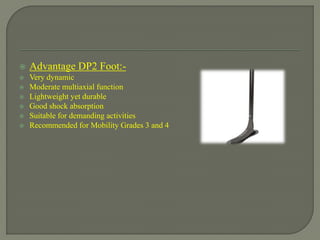
 Advantage DP2 Foot:-
 Very dynamic
 Moderate multiaxial function
 Lightweight yet durable
 Good shock absorption
 Suitable for demanding activities
 Recommended for Mobility Grades 3 and 4
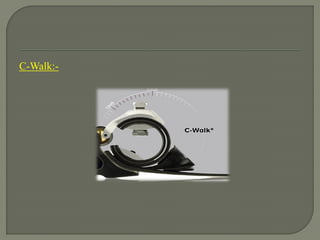
C-Walk:-
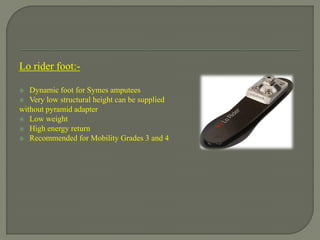
Lo rider foot:-
 Dynamic foot for Symes amputees
 Very low structural height can be supplied
without pyramid adapter
 Low weight
 High energy return
 Recommended for Mobility Grades 3 and 4
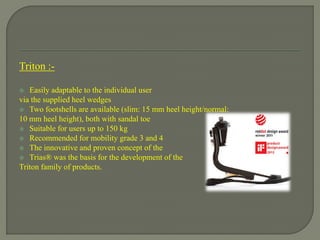
Triton :-
 Easily adaptable to the individual user
via the supplied heel wedges
 Two footshells are available (slim: 15 mm heel height/normal:
10 mm heel height), both with sandal toe
 Suitable for users up to 150 kg
 Recommended for mobility grade 3 and 4
 The innovative and proven concept of the
 Trias® was the basis for the development of the
Triton family of products.
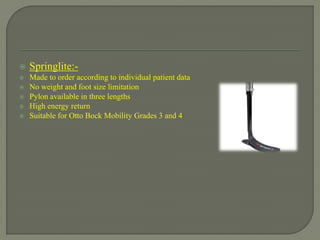
 Springlite:-
 Made to order according to individual patient data
 No weight and foot size limitation
 Pylon available in three lengths
 High energy return
 Suitable for Otto Bock Mobility Grades 3 and 4
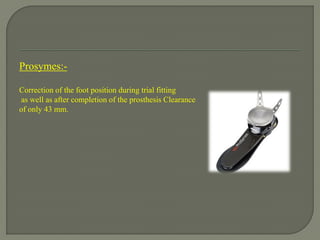
Prosymes:-
Correction of the foot position during trial fitting
as well as after completion of the prosthesis Clearance
of only 43 mm.
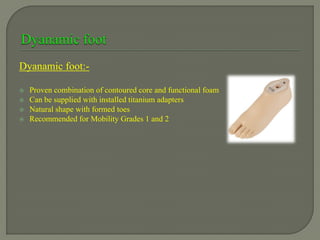
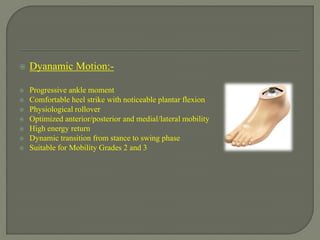
Dyanamic foot:-
 Proven combination of contoured core and functional foam
 Can be supplied with installed titanium adapters
 Natural shape with formed toes
 Recommended for Mobility Grades 1 and 2
 Dyanamic Motion:-
 Progressive ankle moment
 Comfortable heel strike with noticeable plantar flexion
 Physiological rollover
 Optimized anterior/posterior and medial/lateral mobility
 High energy return
 Dynamic transition from stance to swing phase
 Suitable for Mobility Grades 2 and 3
 Greissinger Plus Foot:-
 Multi-axial function to compensate for uneven surfaces
 Individually adjustable due to elastomers in three
degrees of stiffness
 Good rollover properties
 Plantar flexion
 Natural shape
 Suitable for mobility levels 2 and 3
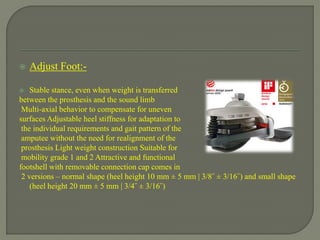
 Adjust Foot:-
 Stable stance, even when weight is transferred
between the prosthesis and the sound limb
Multi-axial behavior to compensate for uneven
surfaces Adjustable heel stiffness for adaptation to
the individual requirements and gait pattern of the
amputee without the need for realignment of the
prosthesis Light weight construction Suitable for
mobility grade 1 and 2 Attractive and functional
footshell with removable connection cap comes in
2 versions – normal shape (heel height 10 mm ± 5 mm | 3/8˝ ± 3/16˝) and small shape
(heel height 20 mm ± 5 mm | 3/4˝ ± 3/16˝)
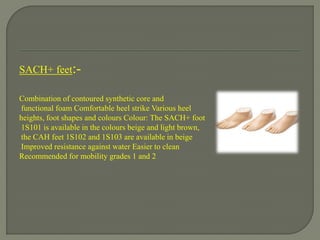
SACH+ feet:-
Combination of contoured synthetic core and
functional foam Comfortable heel strike Various heel
heights, foot shapes and colours Colour: The SACH+ foot
1S101 is available in the colours beige and light brown,
the CAH feet 1S102 and 1S103 are available in beige
Improved resistance against water Easier to clean
Recommended for mobility grades 1 and 2
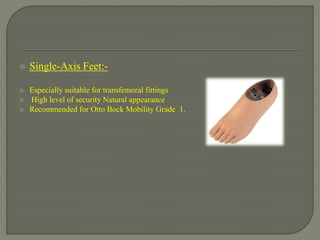
 Single-Axis Feet:-
 Especially suitable for transfemoral fittings
 High level of security Natural appearance
 Recommended for Otto Bock Mobility Grade 1.
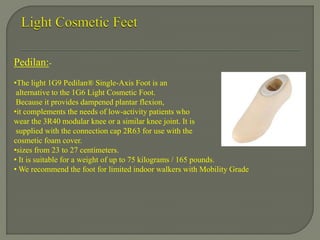
Pedilan:-
•The light 1G9 Pedilan® Single-Axis Foot is an
alternative to the 1G6 Light Cosmetic Foot.
Because it provides dampened plantar flexion,
•it complements the needs of low-activity patients who
wear the 3R40 modular knee or a similar knee joint. It is
supplied with the connection cap 2R63 for use with the
cosmetic foam cover.
•sizes from 23 to 27 centimeters.
• It is suitable for a weight of up to 75 kilograms / 165 pounds.
• We recommend the foot for limited indoor walkers with Mobility Grade
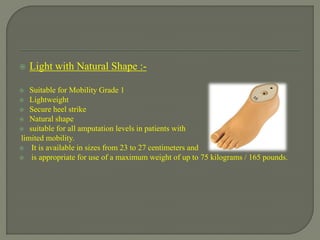
 Light with Natural Shape :-
 Suitable for Mobility Grade 1
 Lightweight
 Secure heel strike
 Natural shape
 suitable for all amputation levels in patients with
limited mobility.
 It is available in sizes from 23 to 27 centimeters and
 is appropriate for use of a maximum weight of up to 75 kilograms / 165 pounds.
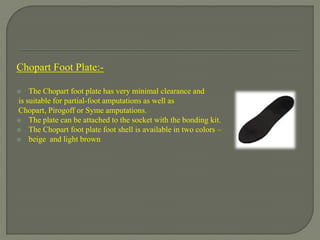
Chopart Foot Plate:-
 The Chopart foot plate has very minimal clearance and
is suitable for partial-foot amputations as well as
Chopart, Pirogoff or Syme amputations.
 The plate can be attached to the socket with the bonding kit.
 The Chopart foot plate foot shell is available in two colors –
 beige and light brown
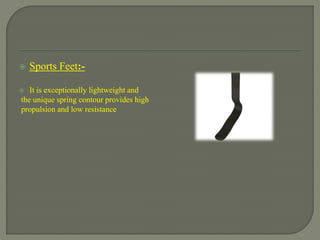
 Sports Feet:-
 It is exceptionally lightweight and
the unique spring contour provides high
propulsion and low resistance
1. Soleus
2. Soleus tactical
3. Velocity
4. Onyx
5. Venture
6. Trustep
7. Tribute
8. Celsus
9. Accent
10. Truper
Ref:- www.collegepark.com
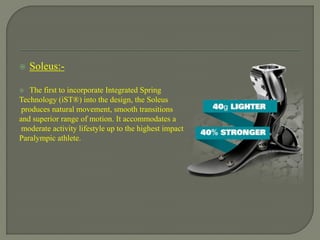
 Soleus:-
 The first to incorporate Integrated Spring
Technology (iST®) into the design, the Soleus
produces natural movement, smooth transitions
and superior range of motion. It accommodates a
moderate activity lifestyle up to the highest impact
Paralympic athlete.