Tandem Connectionist Anomaly Detection: 
Use of Faulty Vibration Signals in Feature 
Representation Learning
1
Takanori
Hasegawa
Jun
Ogata
Tetsuji 
Ogawa
Masahiro
Murakawa
This work was partly supported by the New Energy and Industrial 
Technology Development Organization (NEDO).
2https://www.nrel.gov/continuum/partnering/wind.html
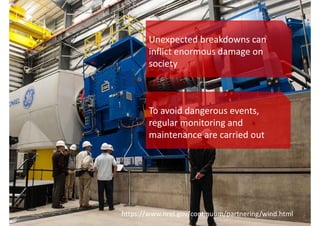
Unexpected breakdowns can 
inflict enormous damage on 
society
To avoid dangerous events, 
regular monitoring and 
maintenance are carried out
3https://www.nrel.gov/continuum/partnering/wind.html
In data‐driven approach, we 
need to collect various types of 
data and build anomaly detector
Many costs in operation
4https://www.nrel.gov/continuum/partnering/wind.html
Effective use of faulty‐state data for 
robust and accurate anomaly 
detection by transferring existing 
system
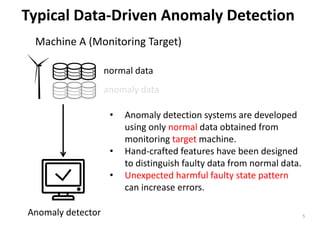
Typical Data‐Driven Anomaly Detection
5
• Anomaly detection systems are developed 
using only normal data obtained from
monitoring target machine.
• Hand‐crafted features have been designed 
to distinguish faulty data from normal data.
• Unexpected harmful faulty state pattern 
can increase errors.
Machine A (Monitoring Target)
normal data
anomaly data
Anomaly detector
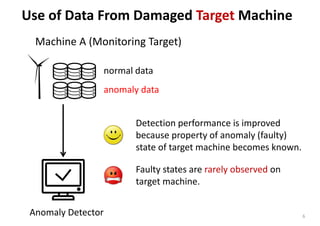
Use of Data From Damaged Target Machine
6
Faulty states are rarely observed on 
target machine.
Detection performance is improved 
because property of anomaly (faulty) 
state of target machine becomes known.
Machine A (Monitoring Target)
normal data
anomaly data
Anomaly Detector
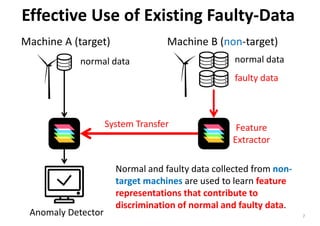
Effective Use of Existing Faulty‐Data
7
normal data
Machine A (target)
normal data
faulty data
Feature
Extractor
System Transfer
Machine B (non‐target)
Normal and faulty data collected from non‐
target machines are used to learn feature 
representations that contribute to 
discrimination of normal and faulty data.
Anomaly Detector
Proposed 
Method
8
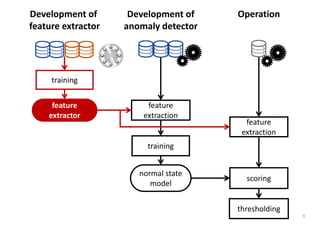
9
training
normal state 
model
feature 
extraction
scoring
thresholding
Development of
anomaly detector
OperationDevelopment of 
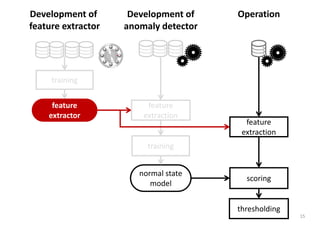
feature extractor
training
feature 
extractor
feature 
extraction
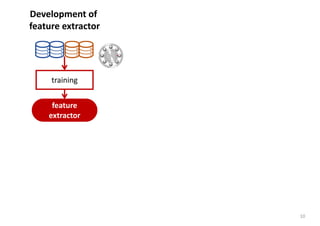
10
Development of 
feature extractor
training
feature 
extractor
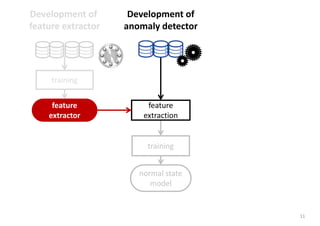
11
training
normal state 
model
Development of
anomaly detector
Development of 
feature extractor
training
feature 
extractor
feature 
extraction
12
training
normal state 
model
Development of
anomaly detector
Development of 
feature extractor
training
feature 
extractor
feature 
extraction
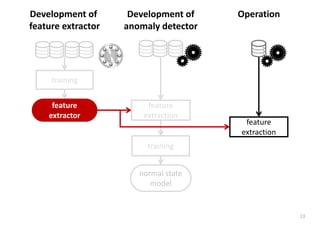
13
training
normal state 
model
feature 
extraction
Development of
anomaly detector
OperationDevelopment of 
feature extractor
training
feature 
extractor
feature 
extraction
14
training
normal state 
model
feature 
extraction
scoring
Development of
anomaly detector
OperationDevelopment of 
feature extractor
training
feature 
extractor
feature 
extraction
15
training
normal state 
model
feature 
extraction
scoring
thresholding
Development of
anomaly detector
OperationDevelopment of 
feature extractor
training
feature 
extractor
feature 
extraction
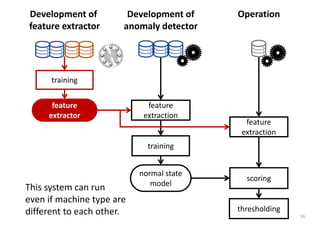
16
training
normal state 
model
feature 
extraction
scoring
thresholding
Development of
anomaly detector
OperationDevelopment of 
feature extractor
training
feature 
extractor
feature 
extraction
This system can run 
even if machine type are 
different to each other.
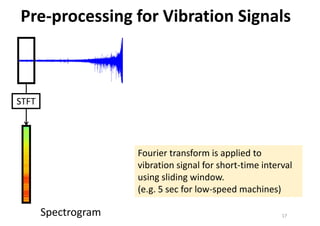
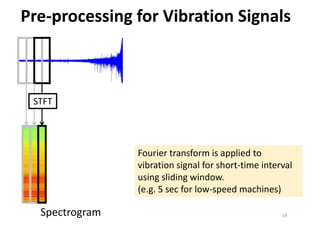
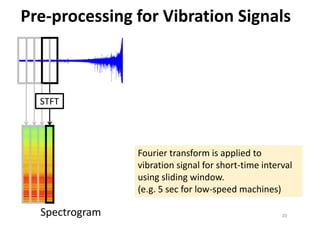
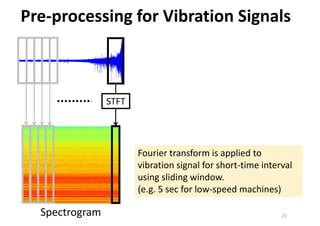
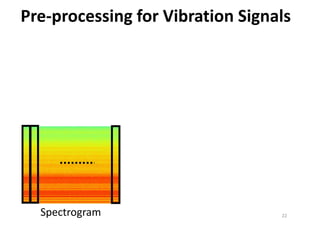
Pre‐processing for Vibration Signals
Spectrogram 17
STFT
Fourier transform is applied to 
vibration signal for short‐time interval 
using sliding window. 
(e.g. 5 sec for low‐speed machines)
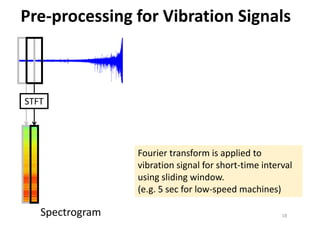
Spectrogram 18
STFT
Pre‐processing for Vibration Signals
Fourier transform is applied to 
vibration signal for short‐time interval 
using sliding window. 
(e.g. 5 sec for low‐speed machines)
Spectrogram 19
STFT
Pre‐processing for Vibration Signals
Fourier transform is applied to 
vibration signal for short‐time interval 
using sliding window. 
(e.g. 5 sec for low‐speed machines)
Spectrogram 20
STFT
Pre‐processing for Vibration Signals
Fourier transform is applied to 
vibration signal for short‐time interval 
using sliding window. 
(e.g. 5 sec for low‐speed machines)
Spectrogram 21
STFT
Pre‐processing for Vibration Signals
Fourier transform is applied to 
vibration signal for short‐time interval 
using sliding window. 
(e.g. 5 sec for low‐speed machines)
Spectrogram 22
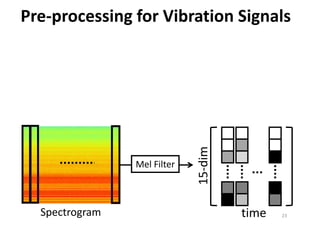
Pre‐processing for Vibration Signals
Spectrogram 23
Mel Filter
Pre‐processing for Vibration Signals
15‐dim
time
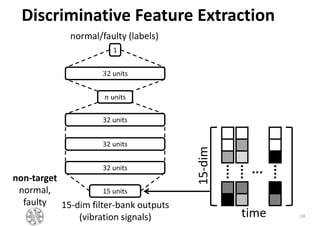
Discriminative Feature Extraction
24
32 units
32 units
32 units
units
32 units
1
15 units
normal/faulty (labels)
non‐target
normal,
faulty 15‐dim filter‐bank outputs
(vibration signals)
15‐dim
time
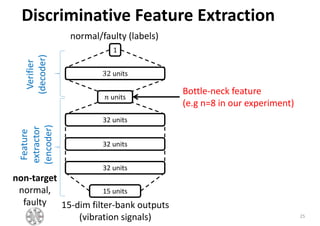
Discriminative Feature Extraction
25
32 units
32 units
32 units
units
32 units
1
15 units
normal/faulty (labels)
non‐target
normal,
faulty
Verifier
(decoder)
Feature
extractor
(encoder)
15‐dim filter‐bank outputs
(vibration signals)
Bottle‐neck feature
(e.g n=8 in our experiment)
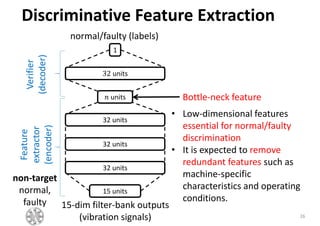
Discriminative Feature Extraction
26
Verifier
(decoder)
Feature
extractor
(encoder)
Bottle‐neck feature
• Low‐dimensional features 
essential for normal/faulty 
discrimination
• It is expected to remove 
redundant features such as 
machine‐specific 
characteristics and operating 
conditions.
32 units
32 units
32 units
units
32 units
1
15 units
normal/faulty (labels)
non‐target
normal,
faulty 15‐dim filter‐bank outputs
(vibration signals)
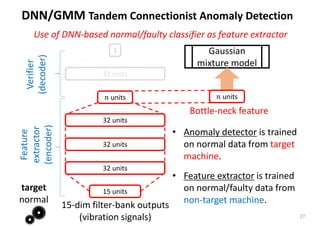
DNN/GMM Tandem Connectionist Anomaly Detection
27
32 units
32 units
32 units
units
32 units
1
15 units
Gaussian 
mixture model
units
Bottle‐neck feature
• Anomaly detector is trained 
on normal data from target 
machine.
• Feature extractor is trained 
on normal/faulty data from 
non‐target machine.
Use of DNN‐based normal/faulty classifier as feature extractor
target
normal
Verifier
(decoder)
Feature
extractor
(encoder)
15‐dim filter‐bank outputs
(vibration signals)
28
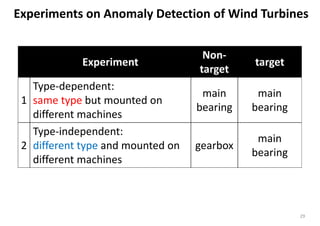
29
Experiment
Non‐
target
target
1
Type‐dependent:
same type but mounted on 
different machines
main 
bearing
main 
bearing
2
Type‐independent:
different type and mounted on 
different machines
gearbox
main 
bearing
Experiments on Anomaly Detection of Wind Turbines
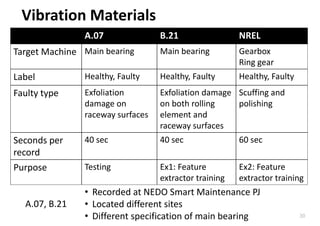
Vibration Materials
A.07 B.21 NREL
Target Machine Main bearing Main bearing Gearbox
Ring gear
Label Healthy, Faulty Healthy, Faulty Healthy, Faulty
Faulty type Exfoliation 
damage on 
raceway surfaces
Exfoliation damage 
on both rolling 
element and 
raceway surfaces
Scuffing and
polishing
Seconds per 
record
40 sec 40 sec 60 sec
Purpose Testing Ex1: Feature 
extractor training
Ex2: Feature 
extractor training
30
• Recorded at NEDO Smart Maintenance PJ
• Located different sites
• Different specification of main bearing
A.07, B.21
31
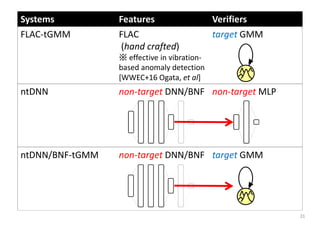
Systems Features Verifiers
FLAC‐tGMM FLAC
(hand crafted)
※ effective in vibration‐
based anomaly detection
[WWEC+16 Ogata, et al]
target GMM
ntDNN non‐target DNN/BNF non‐target MLP
ntDNN/BNF‐tGMM non‐target DNN/BNF target GMM
32
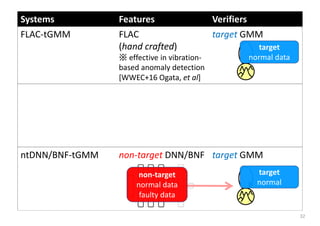
Systems Features Verifiers
FLAC‐tGMM FLAC
(hand crafted)
※ effective in vibration‐
based anomaly detection
[WWEC+16 Ogata, et al]
target GMM
ntDNN/BNF‐tGMM non‐target DNN/BNF target GMM
target
normal
target
normal data
non‐target
normal data
faulty data
33
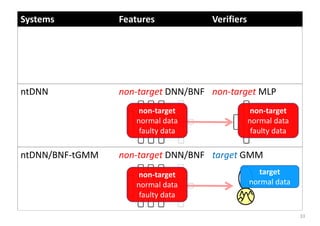
Systems Features Verifiers
FLAC‐tGMM FLAC
(hand crafted)
※振動異常検知におい
て⾼性能
[WWEC+16 Ogata, et al]
target GMM
ntDNN non‐target DNN/BNF non‐target MLP
ntDNN/BNF‐tGMM non‐target DNN/BNF target GMM
target
normal data
non‐target
normal data
faulty data
non‐target
normal data
faulty data
non‐target
normal data
faulty data
34
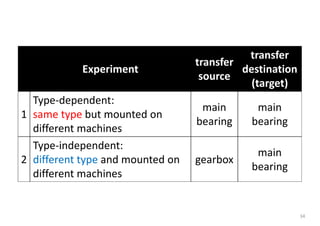
Experiment
transfer
source
transfer
destination
(target)
1
Type‐dependent:
same type but mounted on 
different machines
main 
bearing
main 
bearing
2
Type‐independent:
different type and mounted on 
different machines
gearbox
main 
bearing
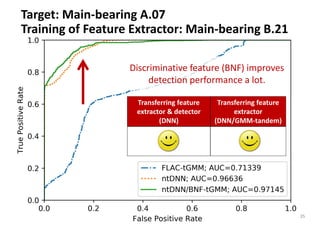
Target: Main‐bearing A.07
Training of Feature Extractor: Main‐bearing B.21
35
Transferring feature 
extractor & detector 
(DNN)
Transferring feature 
extractor
(DNN/GMM‐tandem)
Discriminative feature (BNF) improves 
detection performance a lot.
Target: Main‐bearing A.07
Training of Feature Extractor: Main‐bearing B.21
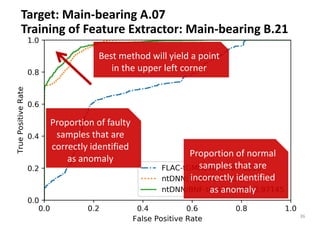
36
Best method will yield a point 
in the upper left corner
Proportion of faulty 
samples that are 
correctly identified 
as anomaly
Proportion of normal 
samples that are 
incorrectly identified 
as anomaly 
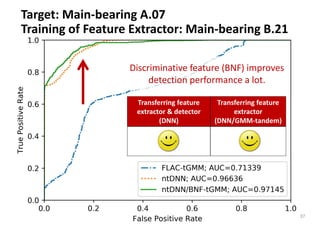
Target: Main‐bearing A.07
Training of Feature Extractor: Main‐bearing B.21
37
Transferring feature 
extractor & detector 
(DNN)
Transferring feature 
extractor
(DNN/GMM‐tandem)
Discriminative feature (BNF) improves 
detection performance a lot.
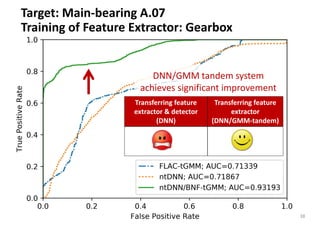
Target: Main‐bearing A.07
Training of Feature Extractor: Gearbox
38
DNN/GMM tandem system 
achieves significant improvement
Transferring feature 
extractor & detector 
(DNN)
Transferring feature 
extractor
(DNN/GMM‐tandem)
39
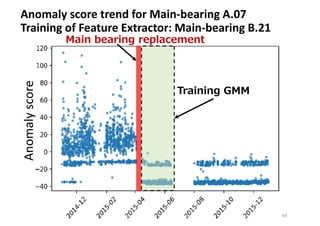
Anomaly score trend for Main‐bearing A.07
Training of Feature Extractor: Main‐bearing B.21Anomalyscore
Main bearing replacement
Training GMM
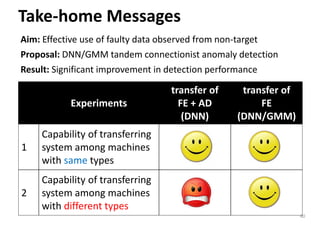
Take‐home Messages
40
Aim: Effective use of faulty data observed from non‐target
Proposal: DNN/GMM tandem connectionist anomaly detection
Result: Significant improvement in detection performance
Experiments
transfer of 
FE + AD
(DNN)
transfer of
FE
(DNN/GMM)
1
Capability of transferring 
system among machines 
with same types
2
Capability of transferring 
system among machines 
with different types