Prototyping Efficient
Machines: Translational &
Rotational Motion
Discover how physics principles can transform your machine
designs. We'll explore motion fundamentals to build smarter,
more efficient prototypes.
by ANGELIQUE TOLENTINO DEL ROSARIO
Simple Machines: The Building Blocks
Lever
Rigid bar that pivots around a
fulcrum to amplify force.
Pulley
Wheel with groove that redirects
force through ropes or cables.
Wheel & Axle
Rotating disk fixed to a central
rod for mechanical advantage.
Inclined Plane
Sloped surface reducing force
needed to raise objects.
Screw
Inclined plane wrapped around a
cylinder, converting rotation to
translation.
Wedge
Two inclined planes back-to-
back, converting force direction.
Why Motion Types Matter in Machine Design
Energy Efficiency
Matching the right motion type to your task
minimizes energy losses through friction and heat.
Smart design choices can increase efficiency by up to
30% in mechanical systems.
Motion Conversion
Many machines need to convert between motion
types:
• Gears: rotational to rotational at different speeds
• Cam: rotational to reciprocating linear
• Crank: rotational to linear and back
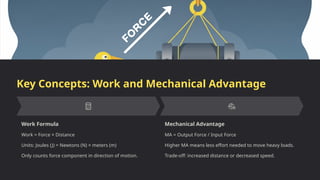
Key Concepts: Work and Mechanical Advantage
Work Formula
Work = Force × Distance
Units: Joules (J) = Newtons (N) × meters (m)
Only counts force component in direction of motion.
Mechanical Advantage
MA = Output Force / Input Force
Higher MA means less effort needed to move heavy loads.
Trade-off: increased distance or decreased speed.
Levers: Translational Motion in Action
Class 1 Lever
Fulcrum between effort and load.
Examples: seesaw, scissors, crowbar
Class 2 Lever
Load between fulcrum and effort.
Examples: wheelbarrow, nutcracker
Class 3 Lever
Effort between fulcrum and load.
Examples: tweezers, human arm
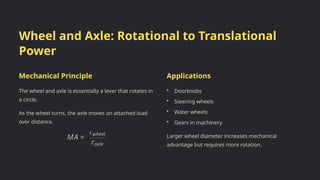
Wheel and Axle: Rotational to Translational
Power
Mechanical Principle
The wheel and axle is essentially a lever that rotates in
a circle.
As the wheel turns, the axle moves an attached load
over distance.
Applications
• Doorknobs
• Steering wheels
• Water wheels
• Gears in machinery
Larger wheel diameter increases mechanical
advantage but requires more rotation.
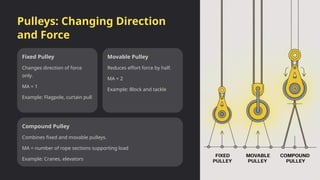
Pulleys: Changing Direction
and Force
Fixed Pulley
Changes direction of force
only.
MA = 1
Example: Flagpole, curtain pull
Movable Pulley
Reduces effort force by half.
MA = 2
Example: Block and tackle
Compound Pulley
Combines fixed and movable pulleys.
MA = number of rope sections supporting load
Example: Cranes, elevators
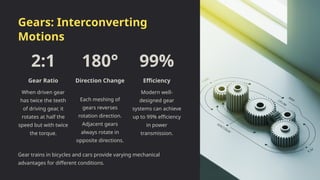
Gears: Interconverting
Motions
2:1
Gear Ratio
When driven gear
has twice the teeth
of driving gear, it
rotates at half the
speed but with twice
the torque.
180°
Direction Change
Each meshing of
gears reverses
rotation direction.
Adjacent gears
always rotate in
opposite directions.
99%
Efficiency
Modern well-
designed gear
systems can achieve
up to 99% efficiency
in power
transmission.
Gear trains in bicycles and cars provide varying mechanical
advantages for different conditions.
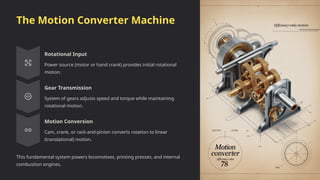
The Motion Converter Machine
Rotational Input
Power source (motor or hand crank) provides initial rotational
motion.
Gear Transmission
System of gears adjusts speed and torque while maintaining
rotational motion.
Motion Conversion
Cam, crank, or rack-and-pinion converts rotation to linear
(translational) motion.
This fundamental system powers locomotives, printing presses, and internal
combustion engines.
Compound Machines: Synergy of Simple
Components
Definition
Compound machines combine two or more simple
machines working together to perform complex tasks.
The output of one simple machine becomes the input
for the next.
Examples
• Bicycle: levers, wheels, pulleys
• Can opener: levers and wedges
• Wheelbarrow: lever and wheel
• Drill press: levers, wheel, screw
Designing an Efficient Prototype:
Selecting Motions
Define Task Requirements
Identify the exact motion needed for your machine's function. Consider load,
distance, speed, and direction.
Match Motion Types
Select appropriate motion type: translational for straight-line movement,
rotational for turning operations.
Identify Conversion Needs
Determine if motion conversion is needed. Match the input motion (power
source) to required output motion.
Select Machine Elements
Choose appropriate simple machines and arrange them to achieve your
motion goals efficiently.
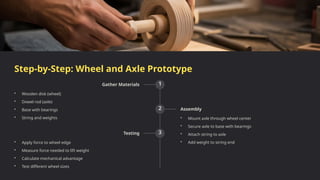
Step-by-Step: Wheel and Axle Prototype
1
Gather Materials
• Wooden disk (wheel)
• Dowel rod (axle)
• Base with bearings
• String and weights
2 Assembly
• Mount axle through wheel center
• Secure axle to base with bearings
• Attach string to axle
• Add weight to string end
3
Testing
• Apply force to wheel edge
• Measure force needed to lift weight
• Calculate mechanical advantage
• Test different wheel sizes
Step-by-Step: Gear Train Prototype
Materials Needed
• Assorted gears (different sizes)
• Mounting board
• Axles or dowels
• Hand crank
• Markers for speed tracking
Assembly & Testing
1. Mount first gear (driver) with crank
2. Position second gear (driven) meshing with first
3. Add markers to track rotation
4. Turn crank and observe speed relationships
5. Calculate gear ratio: teeth_driven ÷ teeth_driver
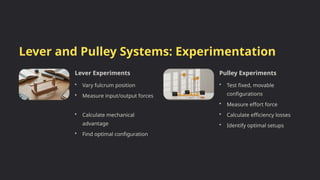
Lever and Pulley Systems: Experimentation
Lever Experiments
• Vary fulcrum position
• Measure input/output forces
• Calculate mechanical
advantage
• Find optimal configuration
Pulley Experiments
• Test fixed, movable
configurations
• Measure effort force
• Calculate efficiency losses
• Identify optimal setups
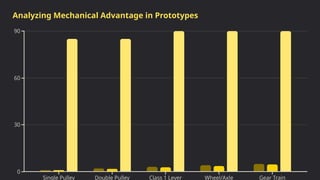
Analyzing Mechanical Advantage in Prototypes
Real-World Applications
Steam Locomotives
Convert heat energy to rotational motion via reciprocating
pistons. Pistons move linearly, then crank converts to wheel
rotation.
Elevator Systems
Use compound pulley arrangements to multiply force. Modern
systems achieve 10:1 mechanical advantage with
counterweights.
Manufacturing
Assembly lines use conveyor belts (wheel/axle) and robotic arms
(levers) to move products through production stages.
Iteration: Testing and Improving Designs
Design
Create initial prototype based on
motion requirements and theoretical
calculations.
Build
Construct prototype using available
materials, ensuring proper
alignment of components.
Test
Measure performance metrics:
mechanical advantage, efficiency,
motion smoothness, speed.
Analyze
Compare results to theoretical
predictions. Identify friction points
and inefficiencies.
Refine
Make targeted improvements based
on test data. Reduce friction,
strengthen weak points.
Future Trends: Smart and Automated Machines
Smart Motion Systems
Modern machines integrate sensors and
microcontrollers to optimize motion.
• Accelerometers detect motion changes
• Force sensors monitor mechanical loads
• Microcontrollers adjust parameters in real-time
Applications
Automated systems revolutionize traditional
mechanisms.
• Self-balancing transportation
• Adaptive prosthetics
• Collaborative robots
• 3D printers combining multiple motion types
Summary & Takeaways
1 Motion Fundamentals
Understanding translational and rotational motion is essential for
efficient machine design.
2 Simple to Complex
Master simple machines first, then combine them into powerful
compound systems.
3 Prototyping Process
Follow systematic build-test-refine cycles to optimize performance
and efficiency.
4 Future Integration
Combine mechanical principles with modern sensors and controls
for next-generation machines.