Controller Principles
1
9AEI-406.9
2
9AEI-406.9
Control System parameters
Control system parameters are
• Error
• Controller output
• Control lag
• Dead time
• Cycling
3
9AEI-406.9
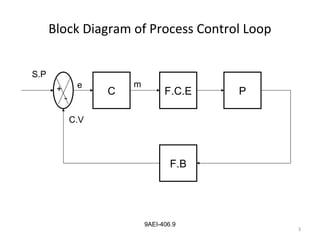
C F.C.E P
F.B
+
-
S.P
C.V
e m
Block Diagram of Process Control Loop
4
9AEI-406.9
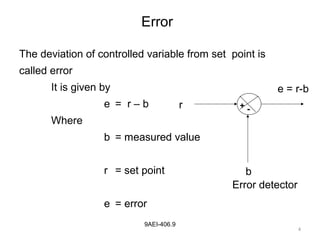
The deviation of controlled variable from set point is
called error
It is given by
e = r – b
Where
b = measured value
r = set point
e = error
Error
+ -r
b
e = r-b
Error detector
5
9AEI-406.9
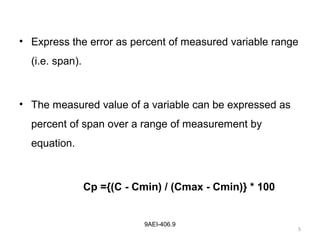
• Express the error as percent of measured variable range
(i.e. span).
• The measured value of a variable can be expressed as
percent of span over a range of measurement by
equation.
Cp ={(C - Cmin) / (Cmax - Cmin)} * 100
6
9AEI-406.9
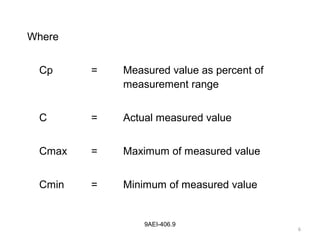
Where
Cp = Measured value as percent of
measurement range
C = Actual measured value
Cmax = Maximum of measured value
Cmin = Minimum of measured value
7
9AEI-406.9
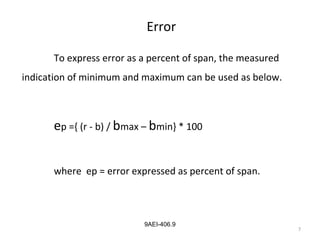
Error
To express error as a percent of span, the measured
indication of minimum and maximum can be used as below.
ep ={ (r - b) / bmax – bmin} * 100
where ep = error expressed as percent of span.
8
9AEI-406.9
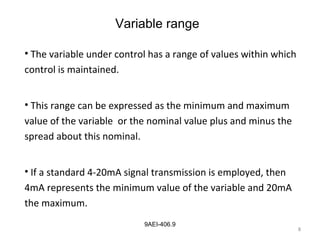
Variable range
• The variable under control has a range of values within which
control is maintained.
• This range can be expressed as the minimum and maximum
value of the variable or the nominal value plus and minus the
spread about this nominal.
• If a standard 4-20mA signal transmission is employed, then
4mA represents the minimum value of the variable and 20mA
the maximum.
8
9
9AEI-406.9
Control parameter range
• The controller output range is the translation of output to the
range of possible values of the final control element.
• This range also is expressed as the 4-20mA standard signal
again with the minimum and maximum effects in terms of the
minimum and maximum current.
9
10
9AEI-406.9
Control lag
• The control system also has a lag associated with its operation
that must be compared to the process lag.
• When a controlled variable experiences a sudden change, the
process-control loop reacts by outputting a command to the
final control element to adopt a new value to compensate for
the detected change.
11
9AEI-406.9
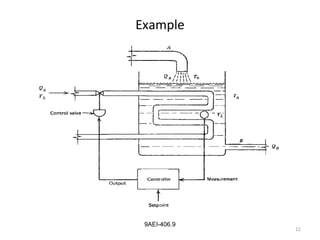
Example
12
9AEI-406.9
Control lag
• “Control lag refers to the time for the process-control loop
to make necessary adjustments to the final control element”.
• If a sudden change in liquid temperature occurs, it
requires some finite time for the control system to physically
actuate the steam control value.
12
13
9AEI-406.9
Dead time
• Time variable associated with process control is both a
function of the process-control system and the process.
• “This is the elapsed time between the instant deviation
(error) occurs and the correction action first occurs”.
14
9AEI-406.9
• An example of dead time occurs in the control of a
chemical reaction by varying reactant flow rate through a
long pipe.
• When a deviation is detected, a control system quickly
changes a value setting to adjust flow rate. but if pipe is
quite long, there is a period of time during which no
effect is felt in the reaction vessel.
15
9AEI-406.9
Dead Time
• This is the time required for the new flow rate to move
down the length of the pipe.
• Such dead times can have a very profound effect on the
performance of control operations on a process.
15
16
9AEI-406.9
Cycling
• Cycling the behavior of the dynamic variable error under
various modes of control.
• One of the most important modes is an oscillation of the
error about zero.
• This means the variable is cycling above and below the
set point value.
• Such cycling may continue indefinitely, in which case we
have ‘steady-state cycling’.
16
17
9AEI-406.9
Cycling
• Here interested in both the peak amplitude of the ‘error
‘and the ‘period of the oscillation’.
• If the cycling amplitude decays to zero, however, we
have a cyclic transient error.
• Here we are interested in the ‘initial error’, the period of
the cyclic oscillation, and ‘decay time’ for the error to reach
zero.
Controller Modes
9AEI-406.10
18
9AEI-406.10
19
Controller Modes
Two modes of control action
• Discontinuous control mode
• Continuous controller
9AEI-406.10
20
Discontinuous control mode
• In Discontinuous mode the controller command
intimates a discontinuous change in in the controller
parameters.
9AEI-406.10
21
Different types of discontinuous modes
•Two position mode
•Multi position mode
•Floating control mode
9AEI-406.10
22
Continuous mode
• In continuous mode, smooth variation of the control
parameters is possible
9AEI-406.10
23
Different types of continuous modes
• Proportional controller (P)
• Integral controller (I)
• Derivative controller (D)
• Composite control modes
9AEI-406.10
24
Composite controller modes
Composite controller modes combine the continuous control modes
Proportional – Integral (PI)
Proportional – Derivative (PD)
Proportional – Integral – Derivative (PID)
9AEI-406.10
25
Control actions
• The error that result from the measurement of the
controlled variable may be positive or negative.
Types of control action
• Direct action
• Reverse action
9AEI-406.10
26
Direct action
• A controller is said to be operated with direct action when
an increasing value of the controller output.
• Example level control system.
• If the level rises (controlled variable increases) the control
output should increase to open the valve more to keep the
level under control.
9AEI-406.10
27
Reverse action
• A control is said to be operating with reverse action when
an increasing value of the controlled variable causes a
decreasing value of the controller output.
• Example a simple temperature control of furnace with
fuel as heat energy.
• If the temperature increases, the control output should
decrease to close the valve for decreasing the fuel input
to bring the temperature under control
28
9AEI-406.11 & 12
ON - OFF Controller
• Two position control is a position type of a controller action in
which manipulated variable is quickly changed to either
maximum (or) minimum value depending upon whether the
controlled variable is greater or less than the set point
• Two position control mode is also called ON – OFF control
mode
28
29
9AEI-406.11 & 12
P = 0% Cp > Sp
= 100% Cp < Sp
P = controller output
Cp = controlling parameter
Sp = set point
The controller output in two position Mode can be
expressed as
Two position mode
30
9AEI-406.11 & 12
ON - OFF Controller
• The minimum value of manipulated variable is zero (off)
• The maximum value is the full amount possible (on)
31
9AEI-406.11 & 12 31
32
9AEI-406.11 & 12
ON - OFF Controller
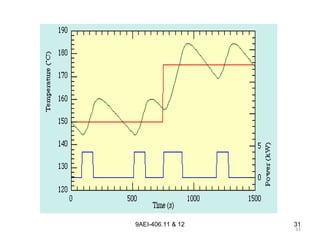
The relation ship shows that
• When the measured value is less than set point, full control
output result.
• When is more than set point, the controller output is zero.
33
9AEI-406.11 & 12
• Liquid bath temperature control
• Level control
• Room heating System
• Air conditioners
Applications
34
9AEI-406.11 & 12
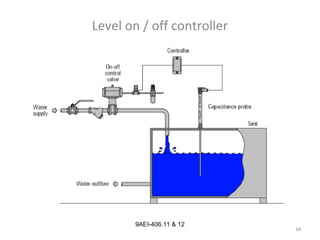
Level on / off controller
35
9AEI-406.11 & 12
36
9AEI-406.11 & 12
37
9AEI-406.11 & 12
Advantages
• Simplest and cheapest.
• Two position controller is suitable for system with slow
process rates.
38
9AEI-406.11 & 12
Disadvantages
• Over shoot and Under shoot resultant continuous oscillation
• Neutral zone
39
9AEI-406.11 & 12
Neutral zone
40
9AEI-406.11 & 12
Neutral zone
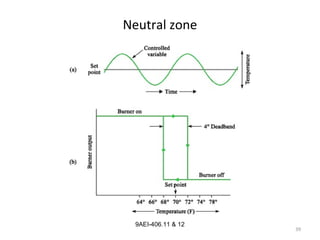
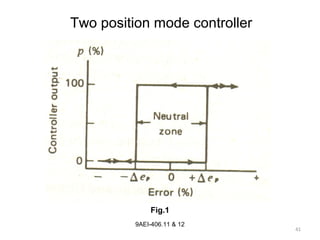
• In practical implementation of the two position controller
• There is an overlap as ep increases through zero or
decreases through zero
• In this span, no change in controller output occurs fig.1
41
9AEI-406.11 & 12
Two position mode controller
Fig.1
42
9AEI-406.11 & 12
• The controller output changes to 100% when the error
changes above Δ ep
• The controller output changes to 0% when the error
changes below Δ ep
Neutral zone
43
9AEI-406.11 & 12
Neutral zone
• The range 2 Δ ep is called as the neutral zone
• This is also called as differential gap
• This is purposefully designed above a certain level
• This prevents excessive cycling
• This is a desirable Hysteresis in a system
9AEI-406.13
44
Multi position mode
• A logical extension of two position control is to provide
several inter mediate rather than only two settings of the
controller output.
• Multi position mode is used to reduce the cycling behavior
and over shoot & undershoot inherent in two position
mode.
9AEI-406.13
45
• A three position mode is one in which the manipulated
variable takes one of three value.
• High
• Medium
• Low
9AEI-406.13
46
Multi position mode
p = pi , e p > ei i = 1,2,3,4---------n
• As Error exceeds ± e i,
Controller output is adjusted to preset values of pi .
• This mode is represented by following equation
9AEI-406.13
47
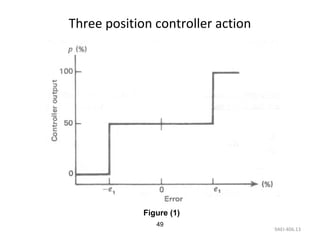
• Three - position controller is best example for multi
position controller
• The controller output in 3- position controller is
P = 100 % e p > e2
= 50 % - e1< e p < e2
= 0 % ep < - e1
Example for multi position controller
9AEI-406.13
48
• As long as the error is between e2 and e1 of the set point
the controller stays at some nominal setting indicated by a
controller output as 50%.
• If the error exceeds the set point by e2 or more then the
output is increased to 100%.
• If the error is less than set point by -e1or more , the
controller output is zero.
• Three position controller action can be shown in figure (1)
9AEI-406.13
49
Three position controller action
Figure (1)
9AEI-406.13
50
Advantages
• Reduce the cycling behavior
• Reduce the overshoots
• Reduce the undershoots
9AEI-406.13
51
Disadvantages
• It requires more complicated final control element (It
requires more than two settings).
52
9AEI-406.14 TO 16
Proportional control
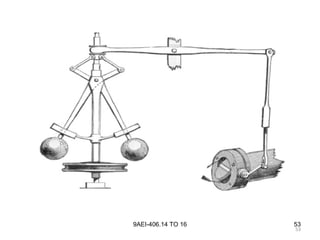
• A proportional control system is a type of linear feedback
control system.
• Two classic mechanical examples are the toilet bowl float
proportioning valve and the fly-ball governor.
53
9AEI-406.14 TO 16 53
54
9AEI-406.14 TO 16
Proportional controller
• Proportional action is a mode of controller action in
which there is a continuous linear relation exist between the
controller and error.
54
55
9AEI-406.14 TO 16
• Proportion action is mode of control action In which there is
a continuous linear relation between value of the deviation
and manipulated variable.
• The action of control variable is repeated and amplified in
the action of the control element.
55
56
9AEI-406.14 TO 16
Proportional controller
Proportional controller also called
• Correspondence controller
• Droop control
• Modulating controller
57
9AEI-406.14 TO 16
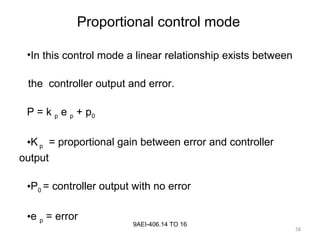
• In the proportional control algorithm, the controller output is
proportional to the error signal, which is the difference
between the set point and the process variable.
• In other words, the output of a proportional controller is the
multiplication product of the error signal and the proportional
gain.
58
9AEI-406.14 TO 16
•In this control mode a linear relationship exists between
the controller output and error.
P = k p e p + p0
•K p = proportional gain between error and controller
output
•P0 = controller output with no error
•e p = error
Proportional control mode
59
9AEI-406.14 TO 16
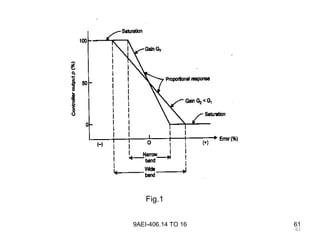
Proportional Band (PB)
•It is defined as the range of error to cover 0% to 100%
controlled output.
60
9AEI-406.14 TO 16 60
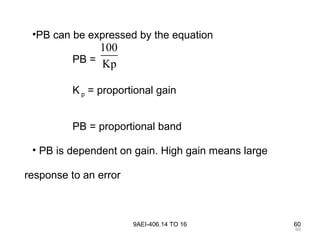
•PB can be expressed by the equation
PB =
K p = proportional gain
PB = proportional band
• PB is dependent on gain. High gain means large
response to an error
100
Kp
61
9AEI-406.14 TO 16 61
Fig.1
62
9AEI-406.14 TO 16
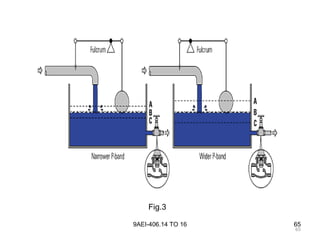
A plot of the proportional mode output verses error shown in
fig.
• Po has been set to 50% and two different gains have been
used.
• Proportional band is depend on the gain.
• A High gain means large response to an error but also a
narrow error band with in which output is not saturated.
• A High percentage of PB (Wide band ) correspond to less
sensitive controller settings.
63
9AEI-406.14 TO 16 63
a) If the error is zero, the output is constant equal to Po.
b) If there is error, for every 1 % of error a correction of Kp
percent is added to or subtracted from Po. depending on
the reverse or direct action of the controller.
The characteristics of proportional mode
64
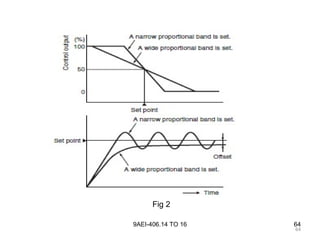
9AEI-406.14 TO 16 64
Fig 2
65
9AEI-406.14 TO 16 65
Fig.3
66
9AEI-406.14 TO 16
Advantages of Proportional Control
• Does not require precise analytical model of the system
being controlled.
• Simple implementation.
• Proper for Applications with simple requirement (Overshoot,
settling time, oscillation and so on).
67
9AEI-406.14 TO 16
Disadvantages of Proportional Control
• Inaccurate model may cause steady-state error nonzero
• Disturbance input is non zero
• Reference input is non zero
• Noise input
• Inaccurate model may cause oscillations.
67
68
9AEI-406.14 TO 16
Applications
• Proportional control generally used in processes where
large load changes are unlikely or with moderate to small
process lag.
69
9AEI-406.14 TO 16
• Offset is a permanent ‘residual error’ in the operating
point of the controlled variable when load change occurs
• Offset can be minimized by a larger value of Kp
(proportional gain).
OFFSET
70
9AEI-406.14 TO 16
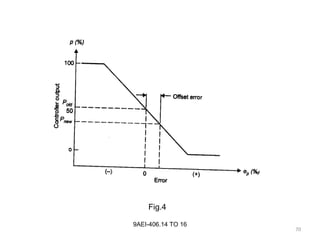
Fig.4
71
9AEI-406.14 TO 16
OFFSET
• consider a system under nominal load with the controller at
50%and the error zero as shown in Fig 2.
• If the transient error occurs the system respond by changing
controller out put in correspondence with the transient to
effect return to zero error
72
9AEI-406.14 TO 16
• If the transient error occurs the system respond by changing
controller out put in correspondence with the transient to
effect return to zero error.
• A load change error that requires a permanent change in
controller output to produce the zero error state.
• One to one correspondence exist between controller out put
and error , it is clear that a new zero controller out put never
be achieved.
• The system produces a small permanent offset in reaching a
compromise position of controller output under new load
73
9AEI-406.14 TO 16
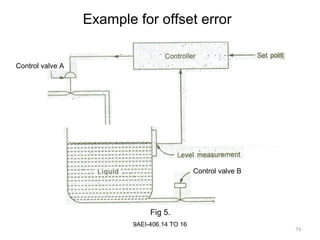
Example for offset error
Fig 5.
Control valve A
Control valve B
74
9AEI-406.14 TO 16
• Consider the proportional mode level control system as
shown in fig 1.
• For understanding the offset error some of the numerical
values regarding proportional controller output and gain
values are assumed.
75
9AEI-406.14 TO 16
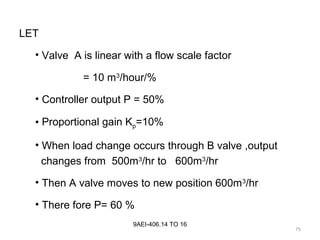
LET
• Valve A is linear with a flow scale factor
= 10 m3
/hour/%
• Controller output P = 50%
• Proportional gain Kp=10%
• When load change occurs through B valve ,output
changes from 500m3
/hr to 600m3
/hr
• Then A valve moves to new position 600m3
/hr
• There fore P= 60 %
76
9AEI-406.14 TO 16
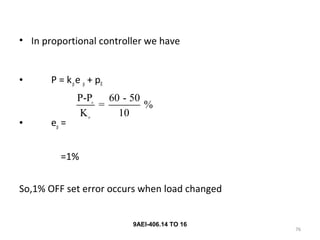
• In proportional controller we have
• P = kpe p + p0
• ep =
=1%
So,1% OFF set error occurs when load changed
0
P
P-P 60 - 50
= %
K 10
77
9AEI-406.14 TO 16
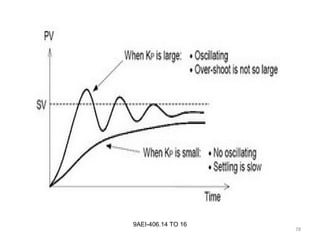
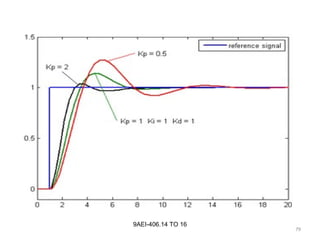
• Offset is eliminated by increase in the proportional gain
which result produces oscillations.
• Fig shows the effect of Kp on the offset.
78
9AEI-406.14 TO 16
79
9AEI-406.14 TO 16
9AEI-406.17 & 18
80
Integral controller
• Integral action is a mode of action in which the value of the
manipulated variable is changed at rate proporonal to the
derivation.
• Integral controller can also be called as Reset Controller.
9AEI-406.17 & 18
81
• If the deviation is double over a previous value , the final
control element is moved twice as faster.
• When the controlled variable is at the set point (zero
deviation), the final control element is stationary.
9AEI-406.17 & 18
82
Integral control mode
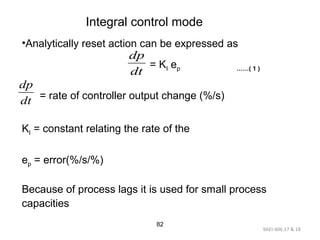
•Analytically reset action can be expressed as
= KI ep ……( 1 )
= rate of controller output change (%/s)
KI = constant relating the rate of the
ep = error(%/s/%)
Because of process lags it is used for small process
capacities
dt
dp
dt
dp
9AEI-406.17 & 18
83
• The inverse of K I, called the integral time Ti =1/Ki,
Expressed in seconds or minutes, is used to describe the
integral mode.
• Ti is defined as the time of change of controlled variable
caused by unit change of deviation.
9AEI-406.17 & 18
84 84
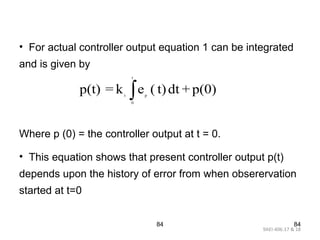
• For actual controller output equation 1 can be integrated
and is given by
Where p (0) = the controller output at t = 0.
• This equation shows that present controller output p(t)
depends upon the history of error from when obserervation
started at t=0
t
t p
0
p(t) = k e ( t)dt + p(0)∫
9AEI-406.17 & 18
85
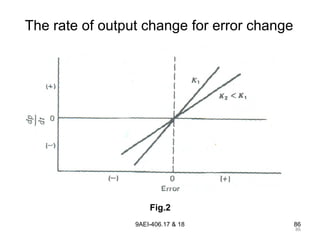
• If the error doubles ,the rate of controller output change also
doubles.
• The constant ki expressed the scaling between error and
controller output.
• A larger value of ki means that small error produces large
rate of change of p and vice versa.
86
9AEI-406.17 & 18 86
The rate of output change for error change
Fig.2
87
9AEI-406.17 & 18 87
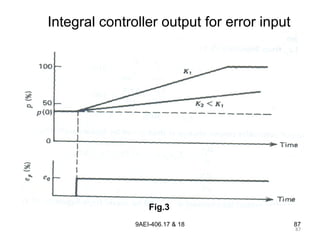
Integral controller output for error input
Fig.3
88
9AEI-406.17 & 18
• We see that the faster rate provided by Ki cause s much
greater control output at a particular time after the error is
generated.
89
9AEI-406.17 & 18
Characteristics of integral controller
• If the error is zero, the output stay fixed at a value to what it
was when error went to zero.
• If the error is not zero, the output will begin to increase or
decrease at a rate of ki percent per second for every one
percentage of error.
90
9AEI-406.17 & 18 90
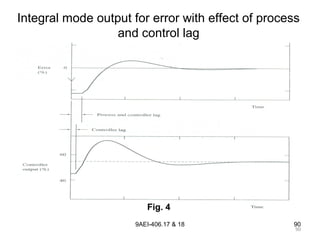
Integral mode output for error with effect of process
and control lag
Fig. 4
91
9AEI-406.17 & 18
Advantages
• Eliminate the offset.
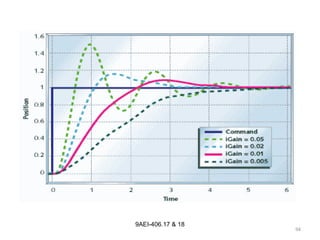
• Produces sluggish and log oscillation responses.
• If increase gain Kp to produce faster response the system
become more oscillatory and may be led to instability.
91
92
9AEI-406.17 & 18
Disadvantages
• Slow response
• Process lag is to large cyclic response
93
9AEI-406.17 & 18
Applications
• The integral control mode is not used alone but can be for
systems with small process lags and correspondingly small
capacities.
94
9AEI-406.17 & 18
9AEI-406.19 & 20
95
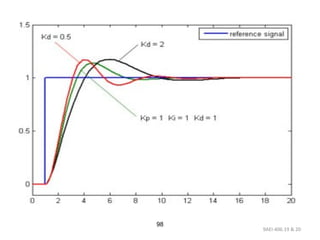
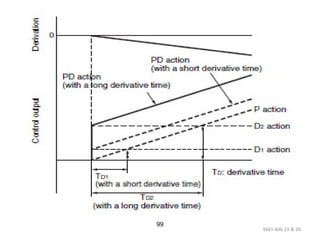
Derivative controller
• The derivative mode of controller operation provides that the
controller output depends on the rate of change of error.
9AEI-406.19 & 20
96
Other Terms of Derivative controller
• Rate response
• Lead component
• Anticipatory controller
9AEI-406.19 & 20
97
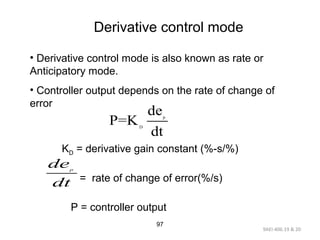
Derivative control mode
• Derivative control mode is also known as rate or
Anticipatory mode.
• Controller output depends on the rate of change of
error
KD = derivative gain constant (%-s/%)
= rate of change of error(%/s)
P = controller output
p
D
de
P=K
dt
p
de
dt
9AEI-406.19 & 20
98
9AEI-406.19 & 20
99
9AEI-406.19 & 20
100
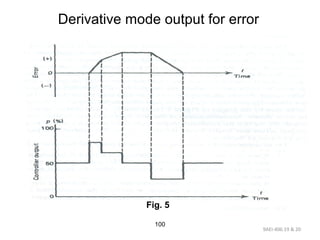
Derivative mode output for error
Fig. 5