Hitoshi Kusano*, Ayaka Kume+, Eiichi Matsumoto+, Jethro Tan+


June 2, 2017
*Kyoto University
+Preferred Networks, Inc.
FCN-Based 6D Robotic Grasping

for Arbitrary Placed Objects
※This work is the output of Preferred Networks internship program
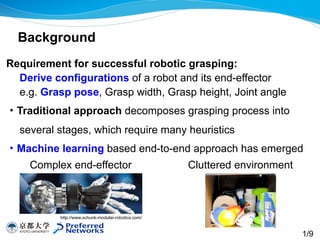
Requirement for successful robotic grasping:

Derive configurations of a robot and its end-effector

e.g. Grasp pose, Grasp width, Grasp height, Joint angle
・Traditional approach decomposes grasping process into
several stages, which require many heuristics
・Machine learning based end-to-end approach has emerged
Background
http://www.schunk-modular-robotics.com/
1/9
Complex end-effector Cluttered environment
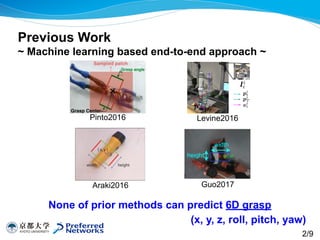
None of prior methods can predict 6D grasp

Previous Work

~ Machine learning based end-to-end approach ~
Pinto2016 Levine2016
Araki2016 Guo2017
(x, y)height
width
2/9
(x, y, z, roll, pitch, yaw)
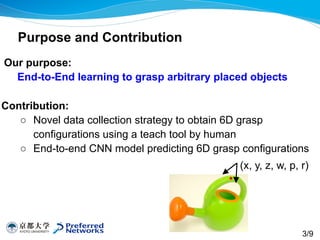
Our purpose:
End-to-End learning to grasp arbitrary placed objects

Contribution:
○ Novel data collection strategy to obtain 6D grasp
configurations using a teach tool by human
○ End-to-end CNN model predicting 6D grasp configurations
Purpose and Contribution
(x, y, z, w, p, r)
3/9
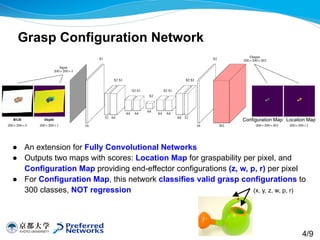
● An extension for Fully Convolutional Networks
● Outputs two maps with scores: Location Map for graspability per pixel, and
Configuration Map providing end-effector configurations (z, w, p, r) per pixel
● For Configuration Map, this network classifies valid grasp configurations to
300 classes, NOT regression
Grasp Configuration Network
(x, y, z, w, p, r)
4/9
Location MapConfiguration Map
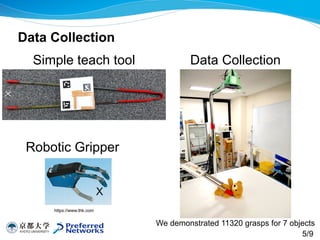
Data Collection
Simple teach tool Data Collection
We demonstrated 11320 grasps for 7 objects
5/9
Robotic Gripper
https://www.thk.com
X
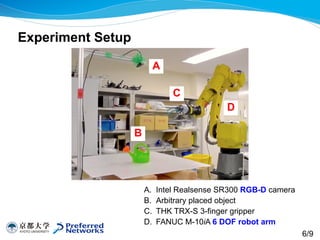
A. Intel Realsense SR300 RGB-D camera
B. Arbitrary placed object
C. THK TRX-S 3-finger gripper
D. FANUC M-10iA 6 DOF robot arm
Experiment Setup
B
C
D
A
6/9
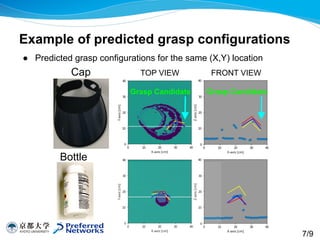
● Predicted grasp configurations for the same (X,Y) location
Example of predicted grasp configurations
Cap
Bottle
TOP VIEW FRONT VIEW
Grasp Candidate Grasp Candidate
7/9
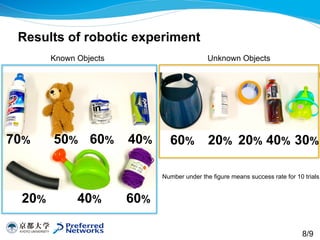
Known Objects Unknown Objects
Results of robotic experiment
70% 50% 60% 40%
20% 40% 60%
Number under the figure means success rate for 10 trials
60% 20% 20% 40% 30%
8/9
_
System Test
※This video is double speed
9/9
Thank you for listening
and
I hope to talk to you in the interactive session